Results
Every figure and table here is read from the repository's figures/ and results/ folders when the site is built, with its caption, sample size and provenance flag. A figure that the latest run could not make says why. The numbers are whatever the last run produced; nothing on this page is typed in by hand.
Phase 3: learned landing, real terrain, plume and rover autonomy
Figures as last produced by experiments/phase3/make_figures_phase3.py; captions, sample sizes and flags from figures/phase3_captions.json. They are regenerated after the final runs, under the same names.
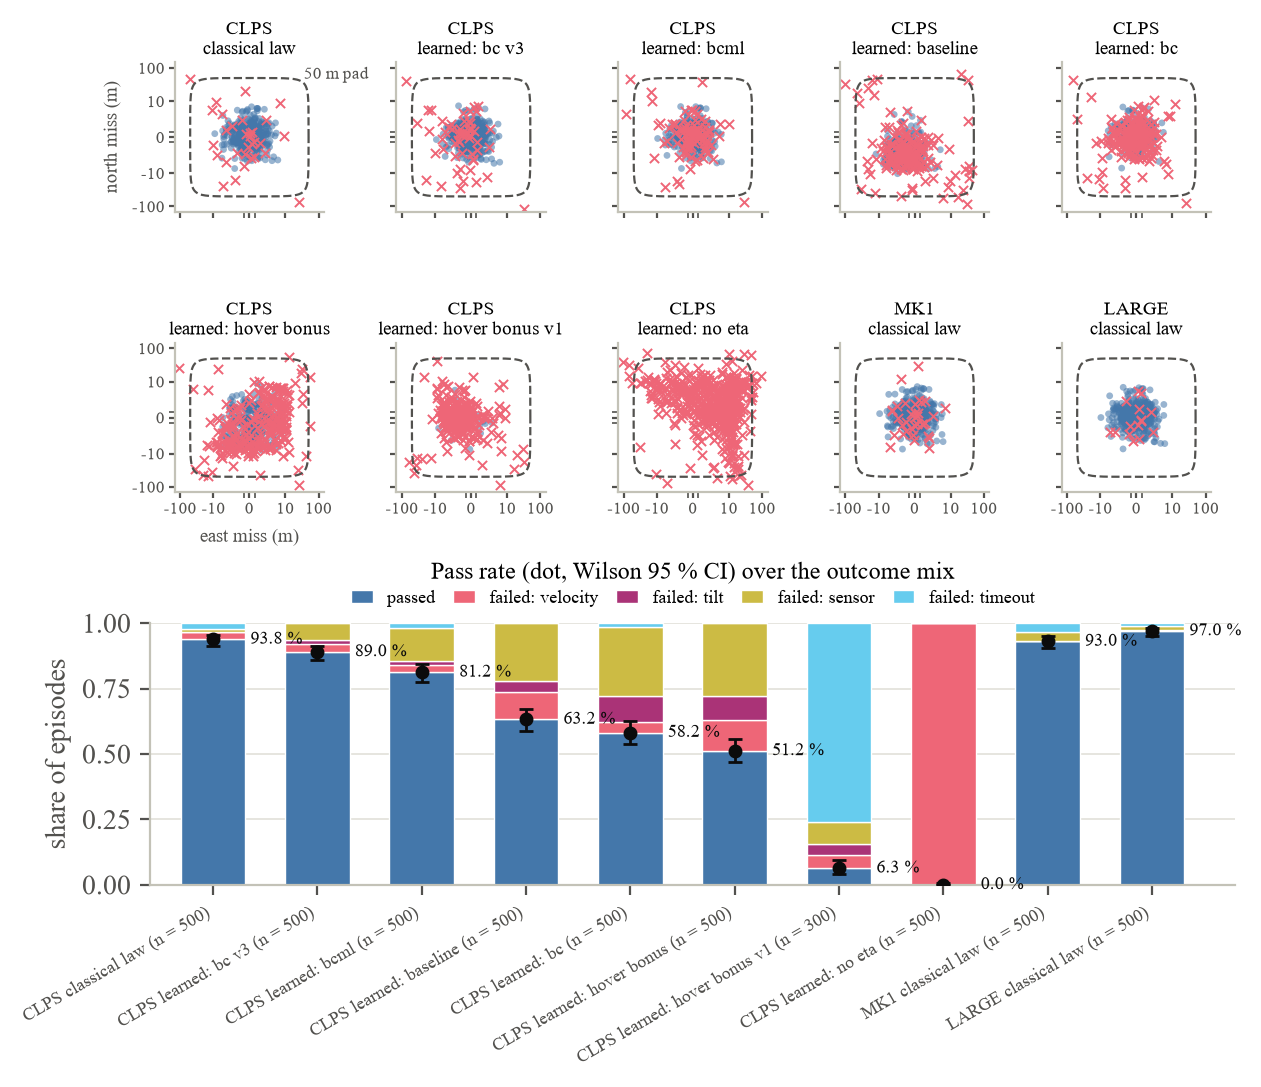
n: CLPS classical law n = 500, CLPS learned: bc v3 n = 500, CLPS learned: bcml n = 500, CLPS learned: baseline n = 500, CLPS learned: bc n = 500, CLPS learned: hover bonus n = 500, CLPS learned: hover bonus v1 n = 300, CLPS learned: no eta n = 500, MK1 classical law n = 500, LARGE classical law n = 500 · Intervals: Wilson 95 % interval on the pass rate · Flags: Modelled / Spec
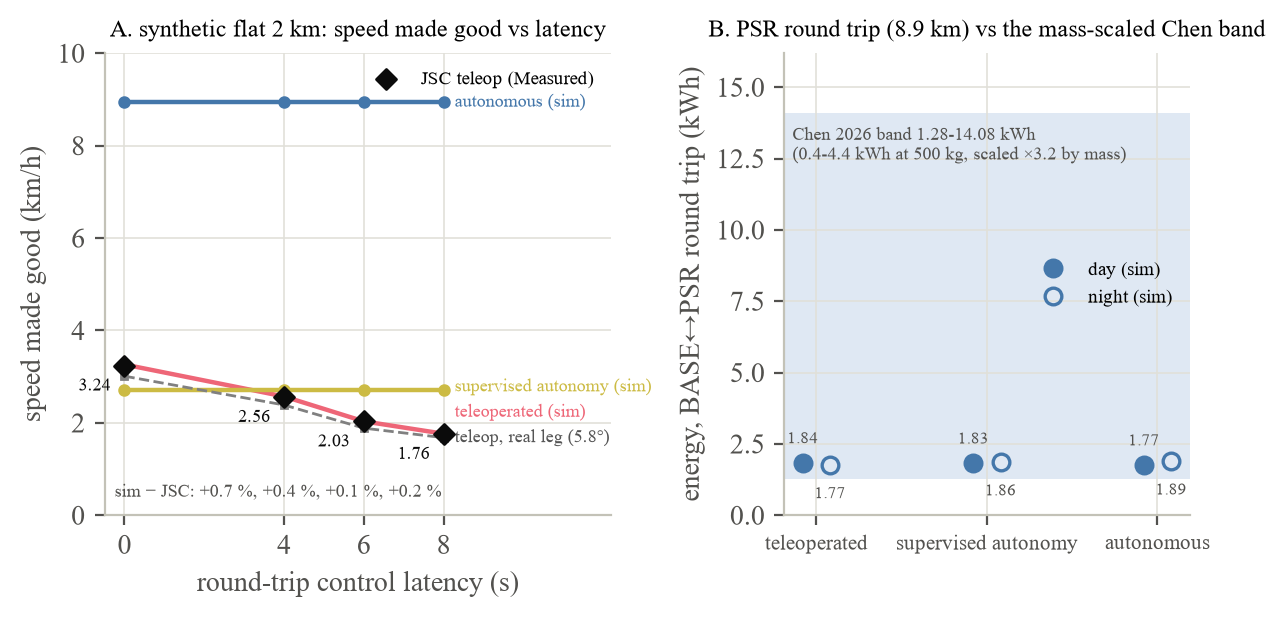
n: deterministic integrator means (no replication) · Intervals: none (point checks) · Flags: Measured anchors, Modelled table, Assumed mass scaling
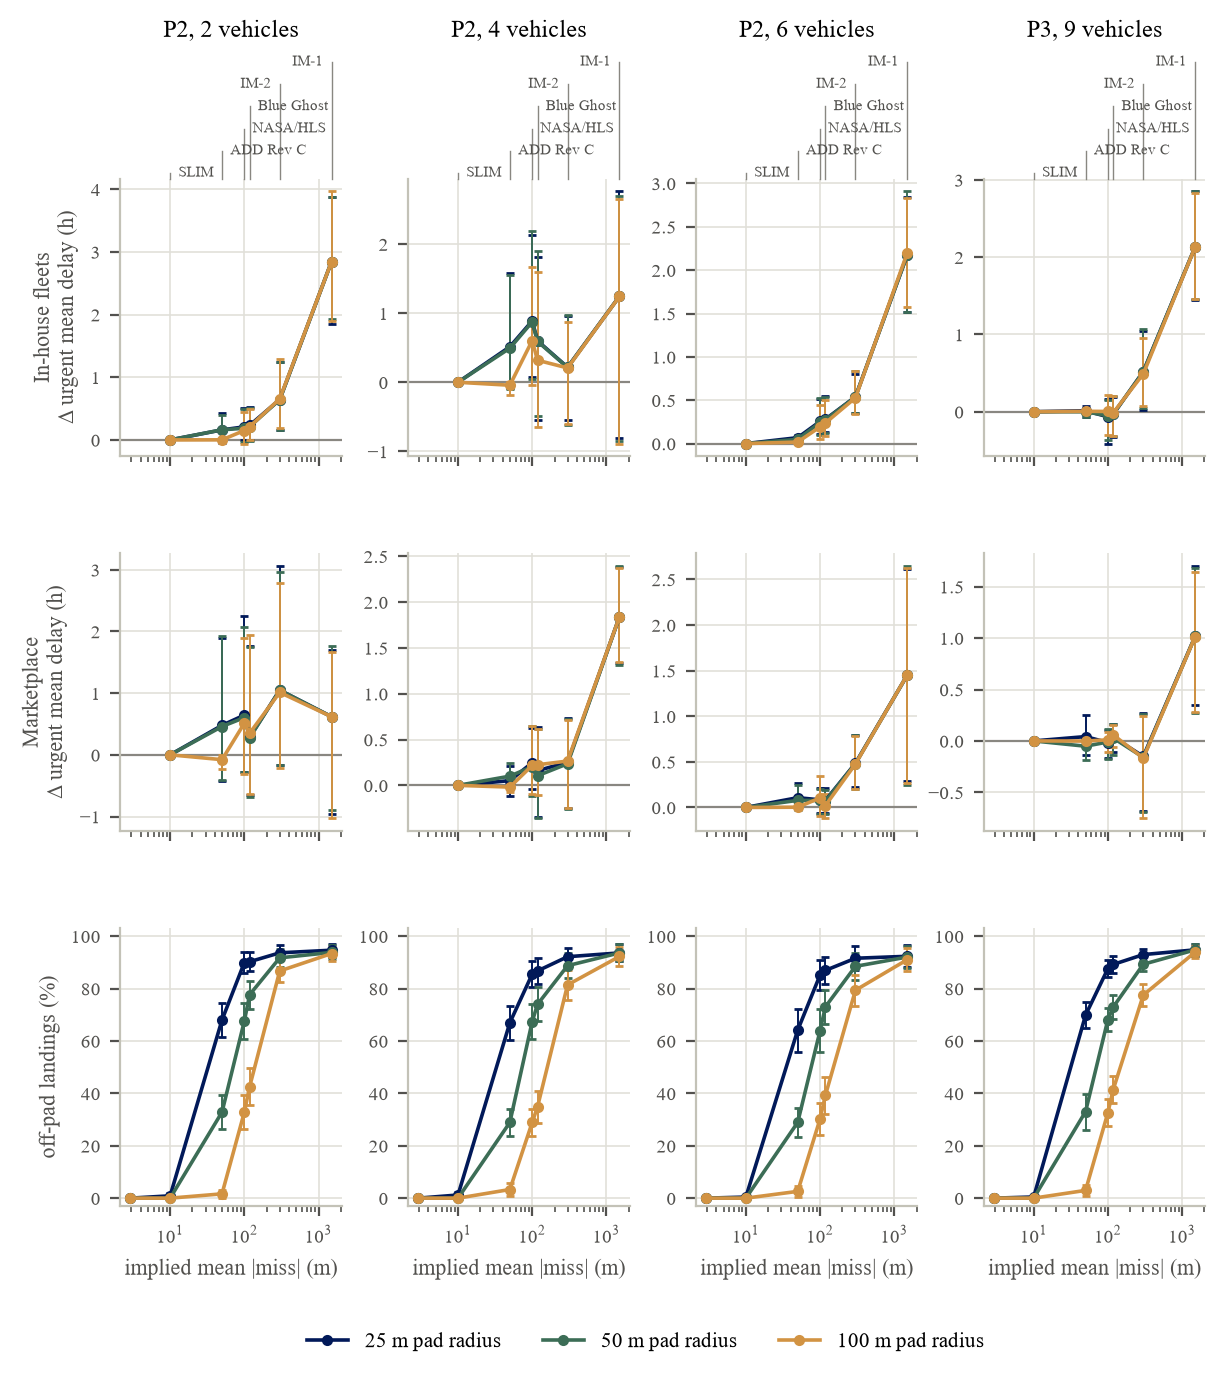
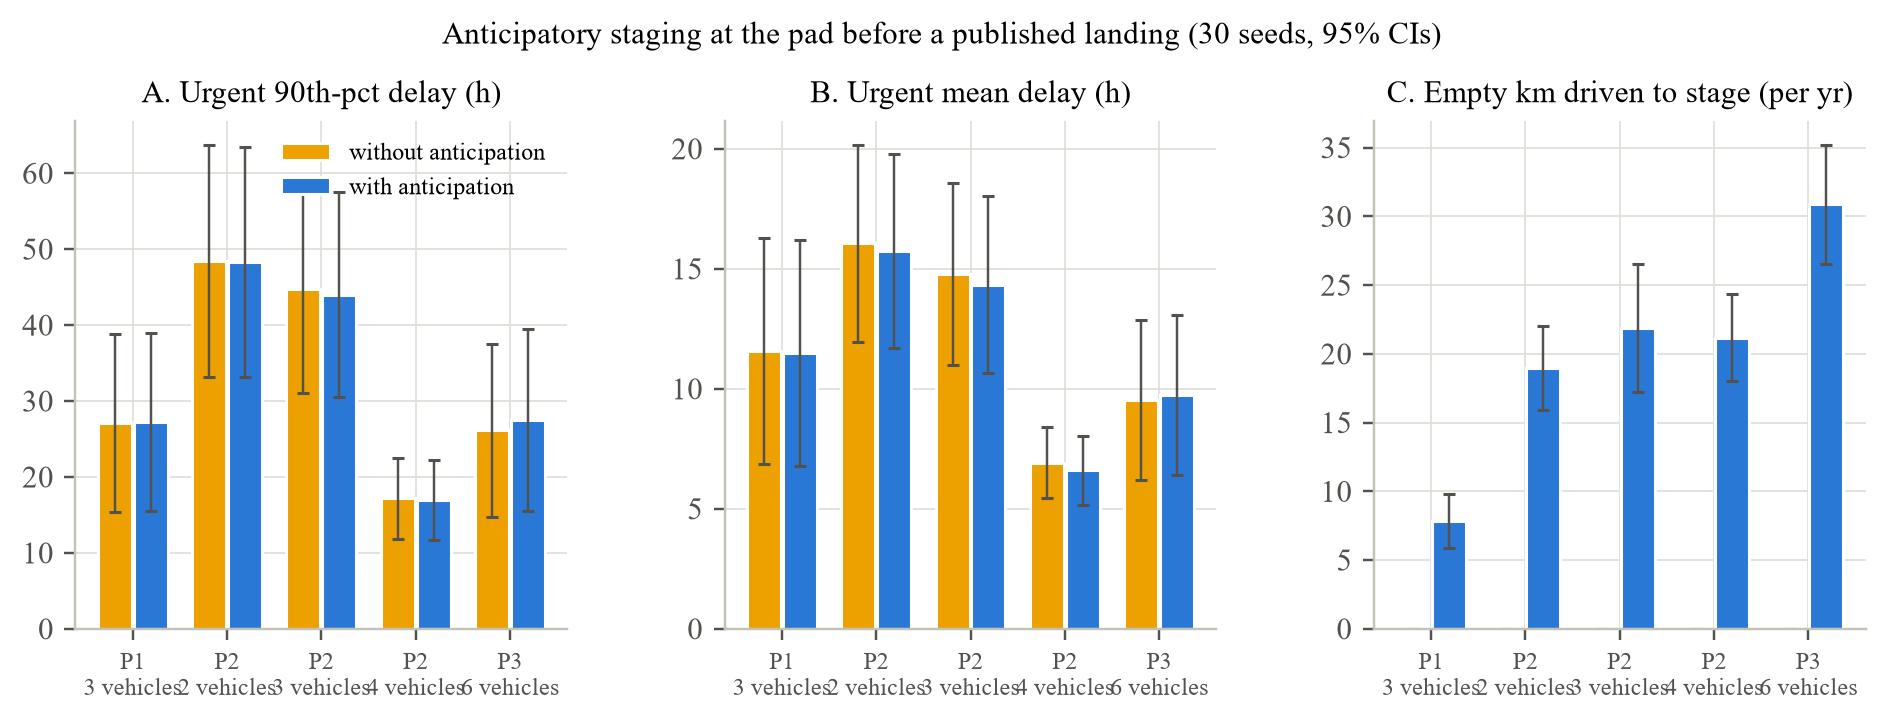
n: n = 30 seeds per cell · Intervals: paired seed-bootstrap 95 % percentile CI; 1.96 SE for shares · Flags: Measured anchors, Spec requirements, Modelled logistics
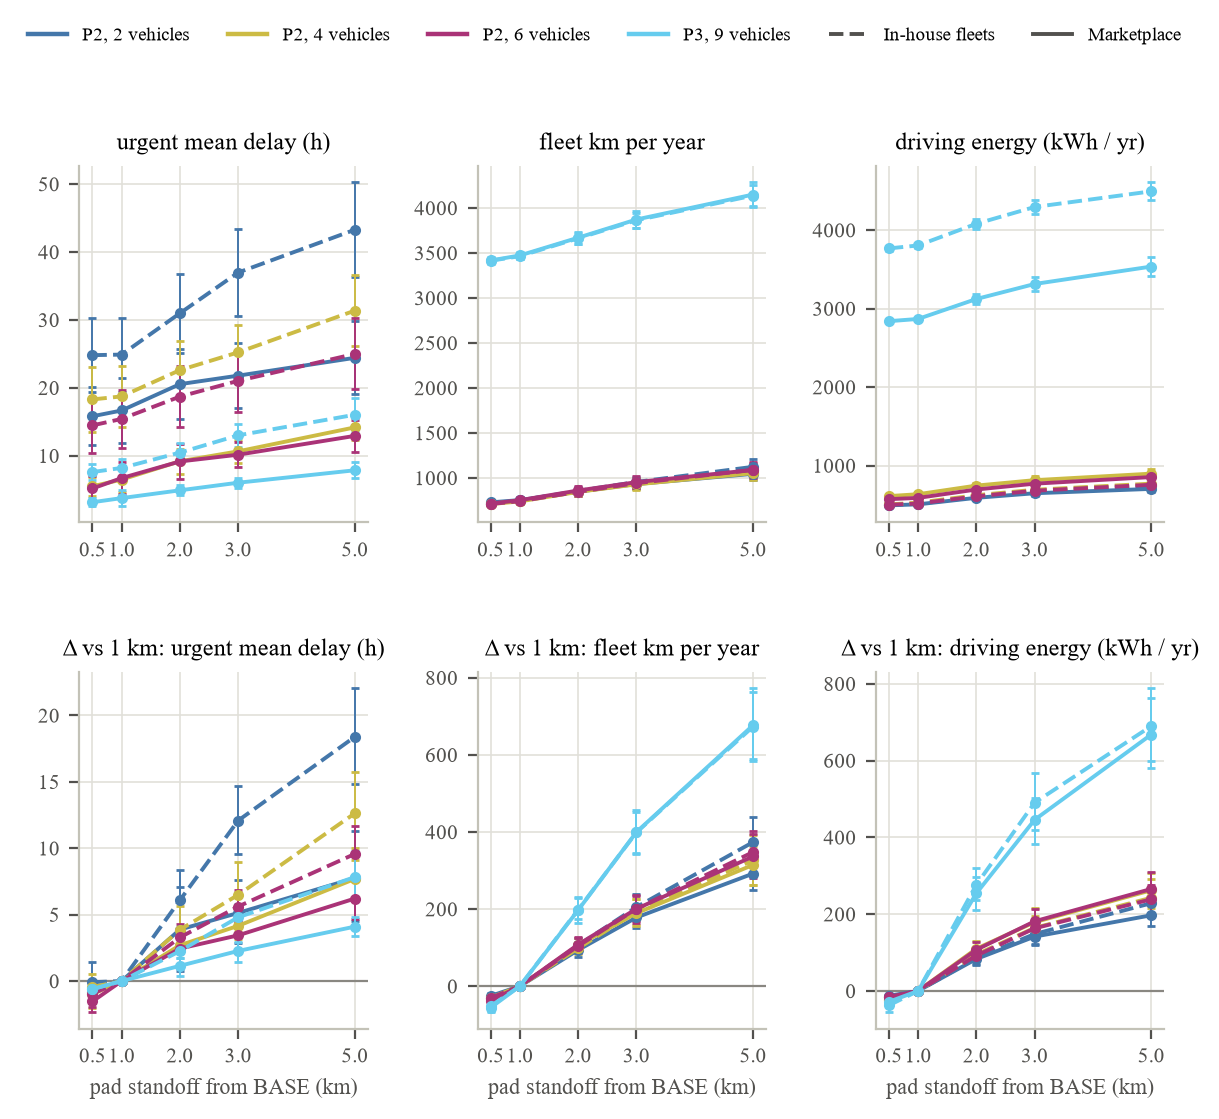
n: n = 30 seeds per cell · Intervals: 95 % CI = 1.96 SE over seeds (means); paired seed-bootstrap 95 % percentile CI (differences) · Flags: Measured terrain, Modelled logistics, Assumed sweep
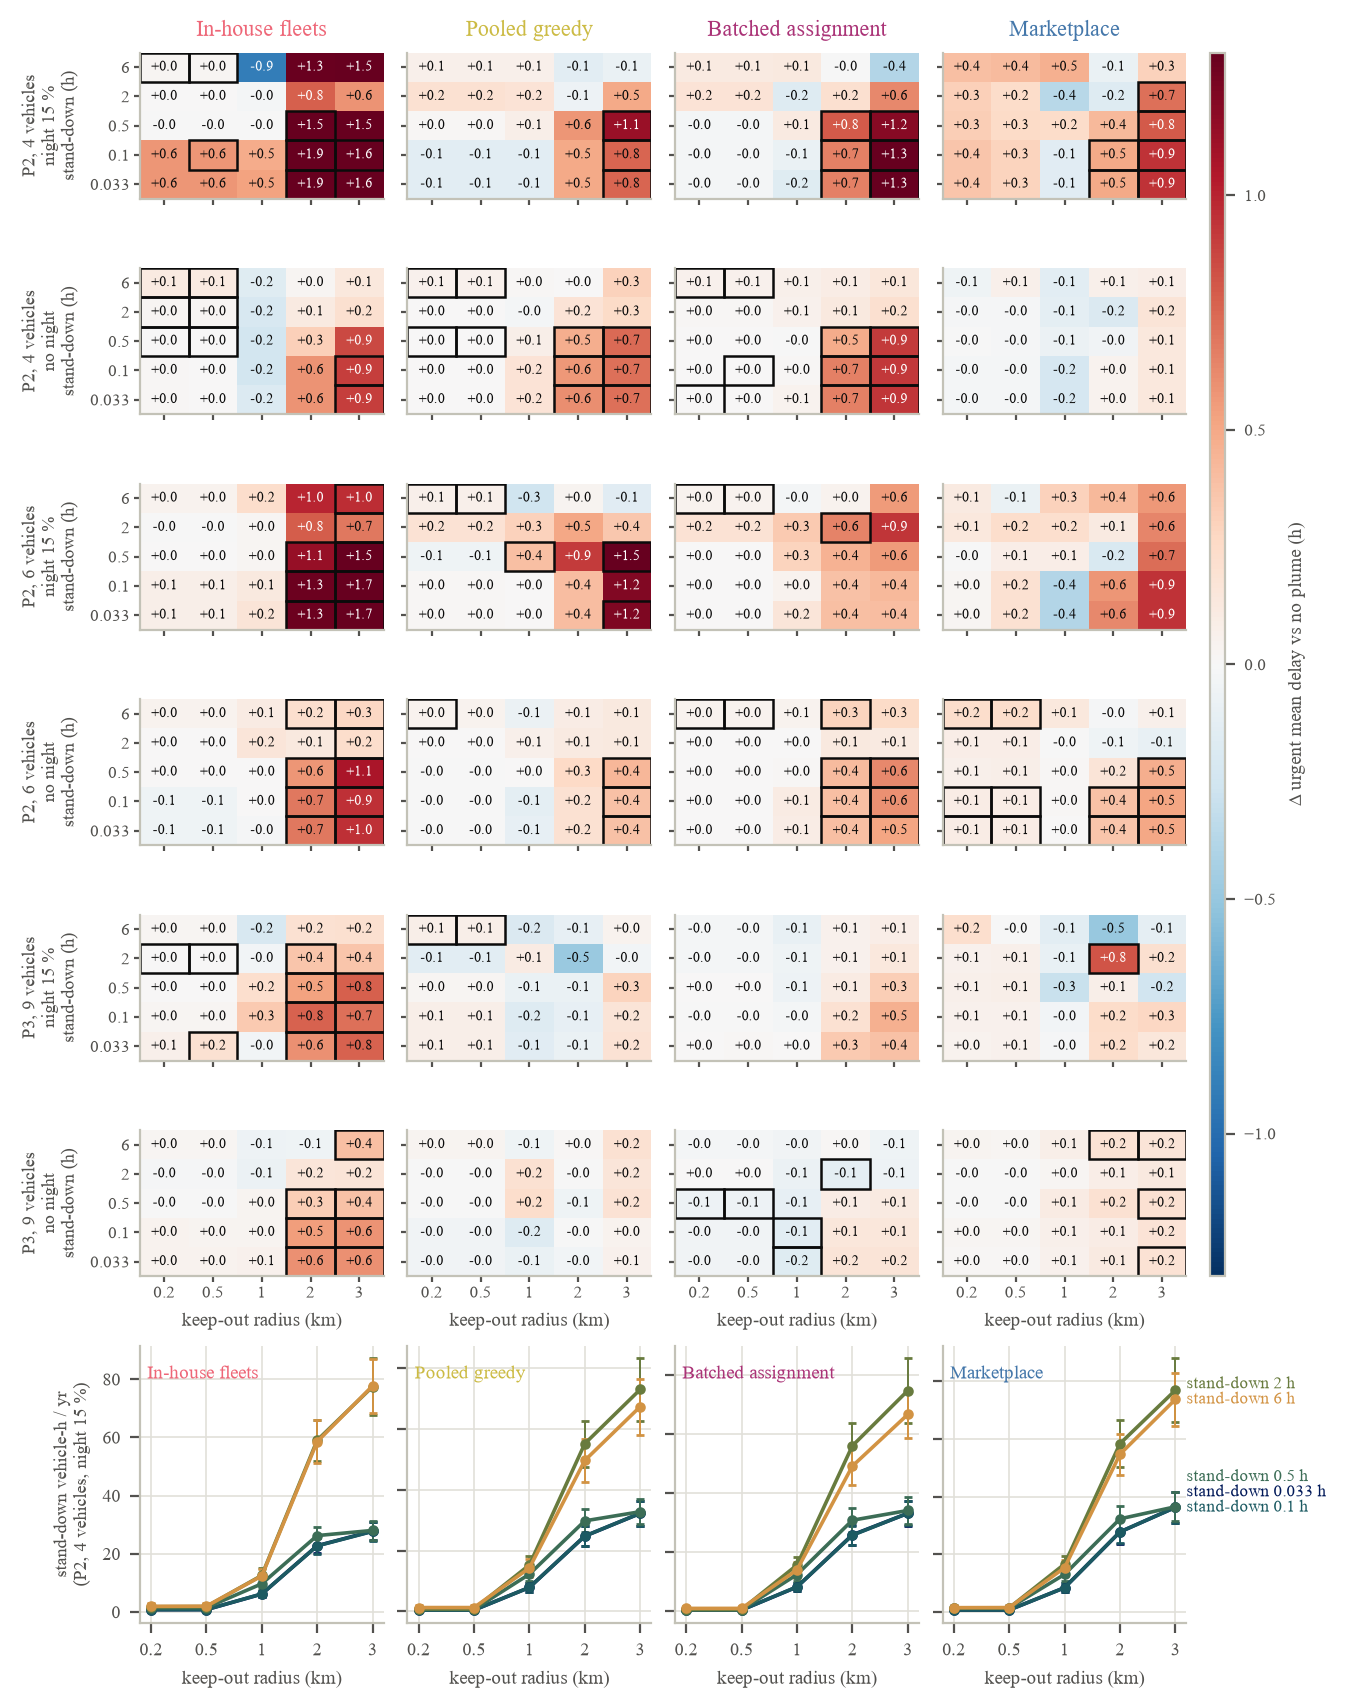
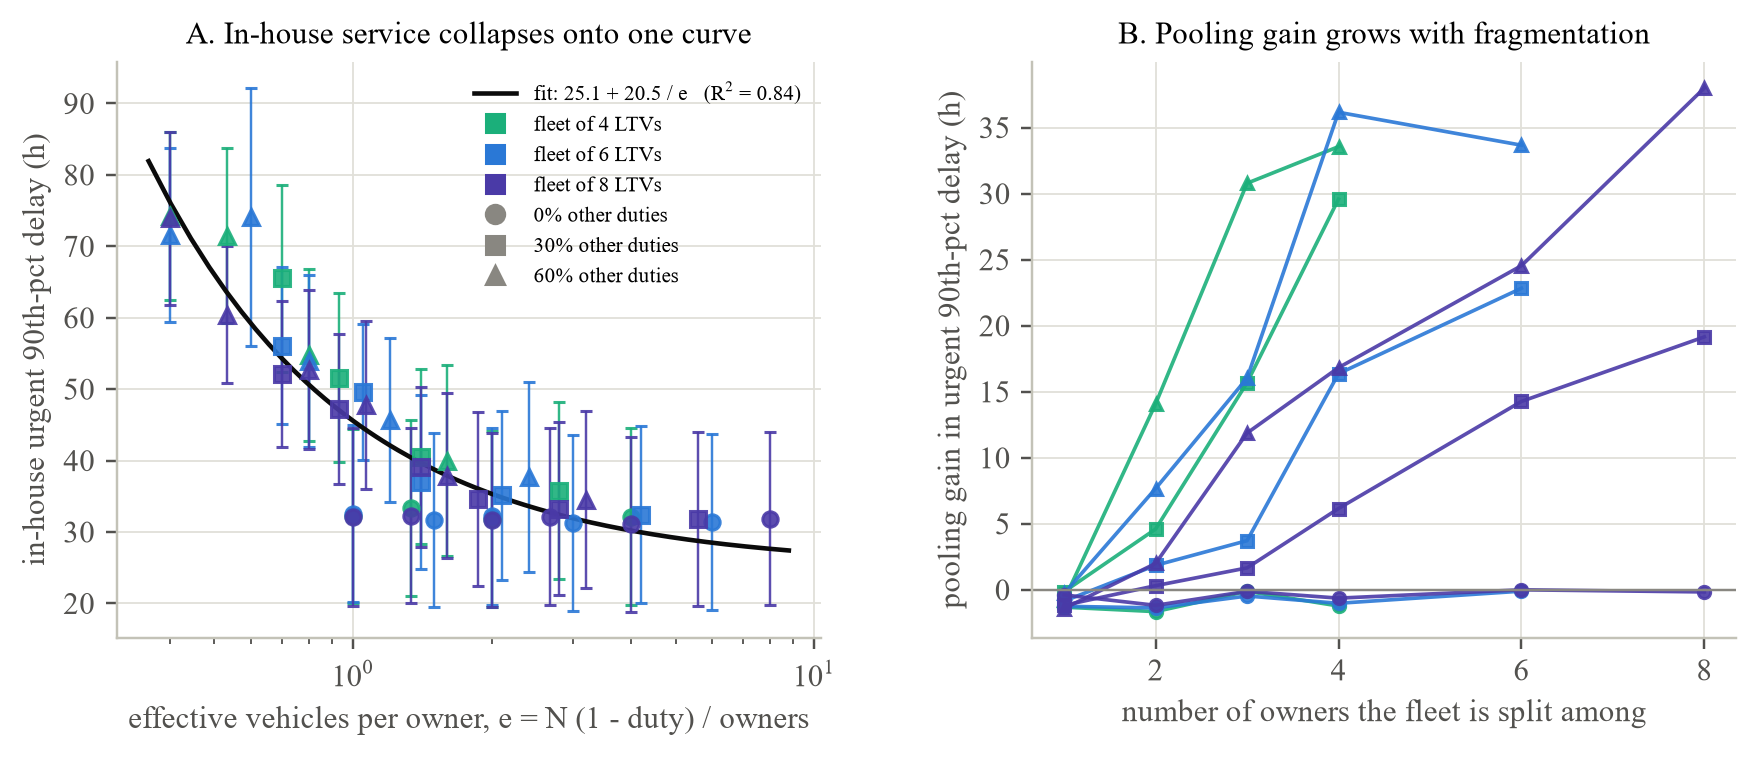
n: n = 30 seeds per cell · Intervals: paired seed-bootstrap 95 % CI (outlined cells exclude 0); 1.96 SE for stand-down hours · Flags: Assumed sweep, Modelled logistics
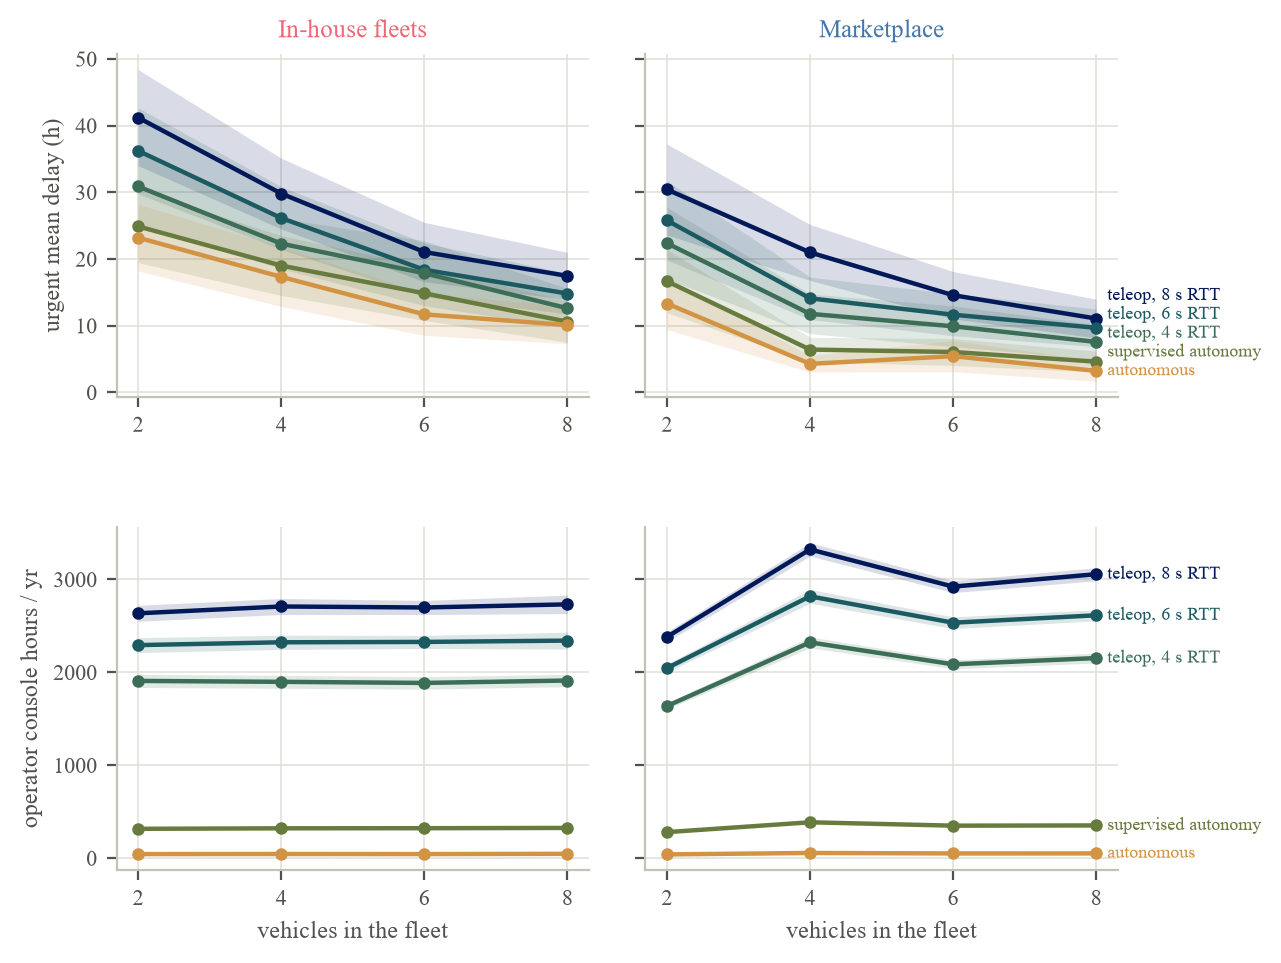
n: n = 30 seeds per cell · Intervals: 95 % CI bands (±1.96 SE over seeds) · Flags: Modelled on Measured JSC curve; Assumed interventions
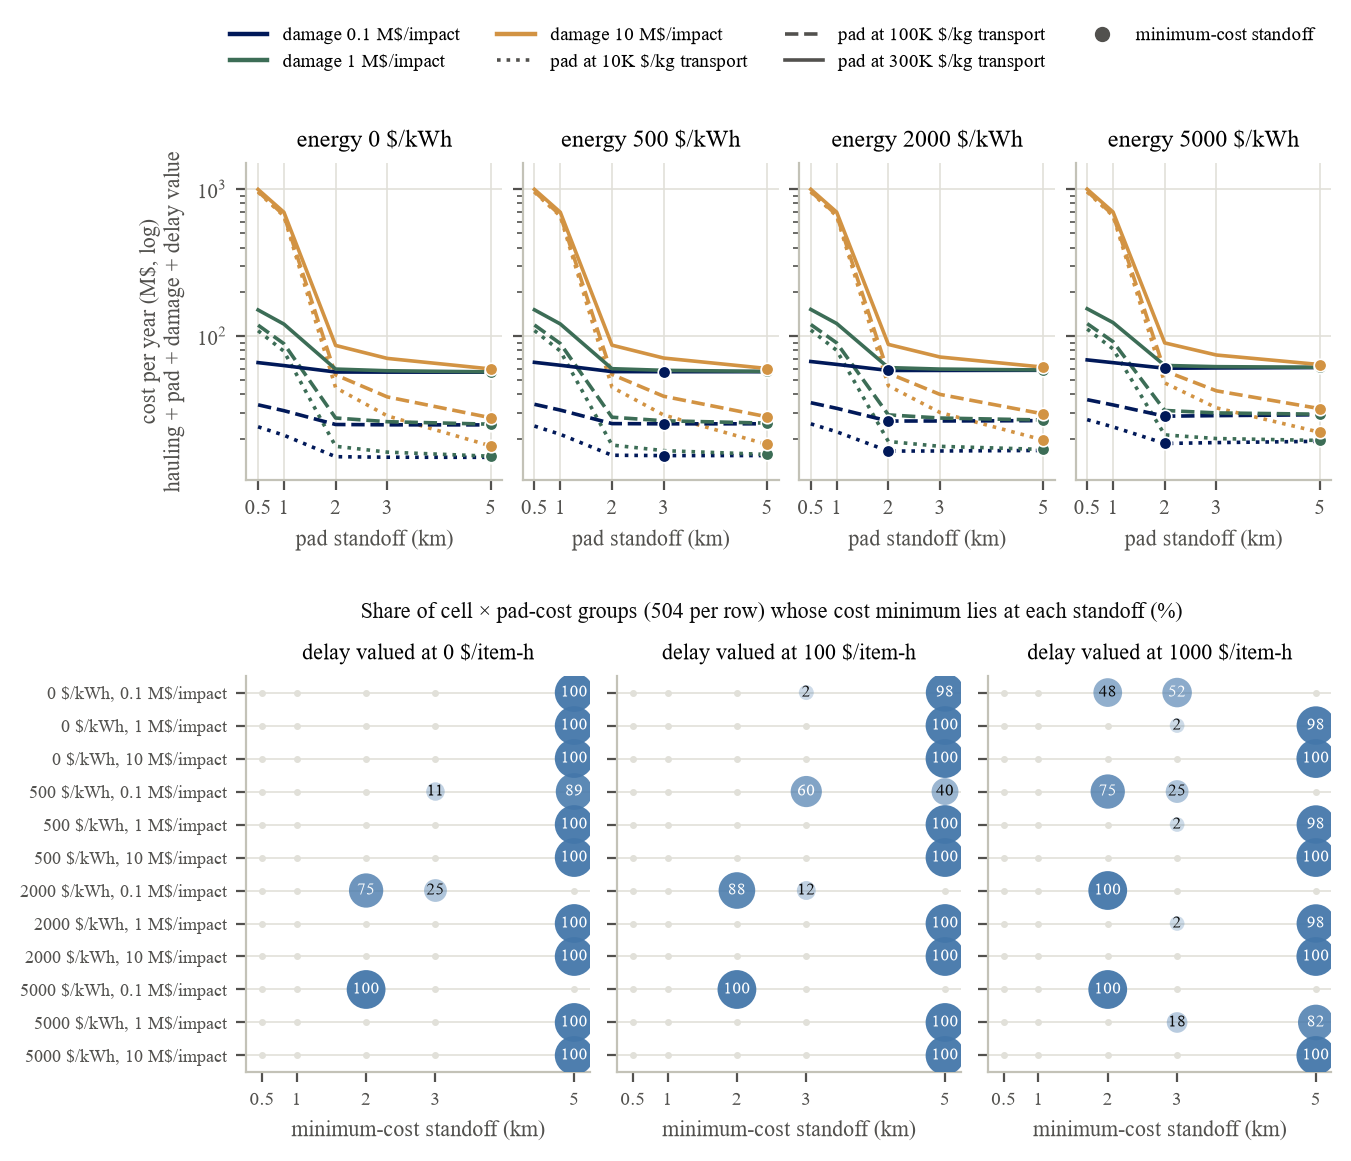
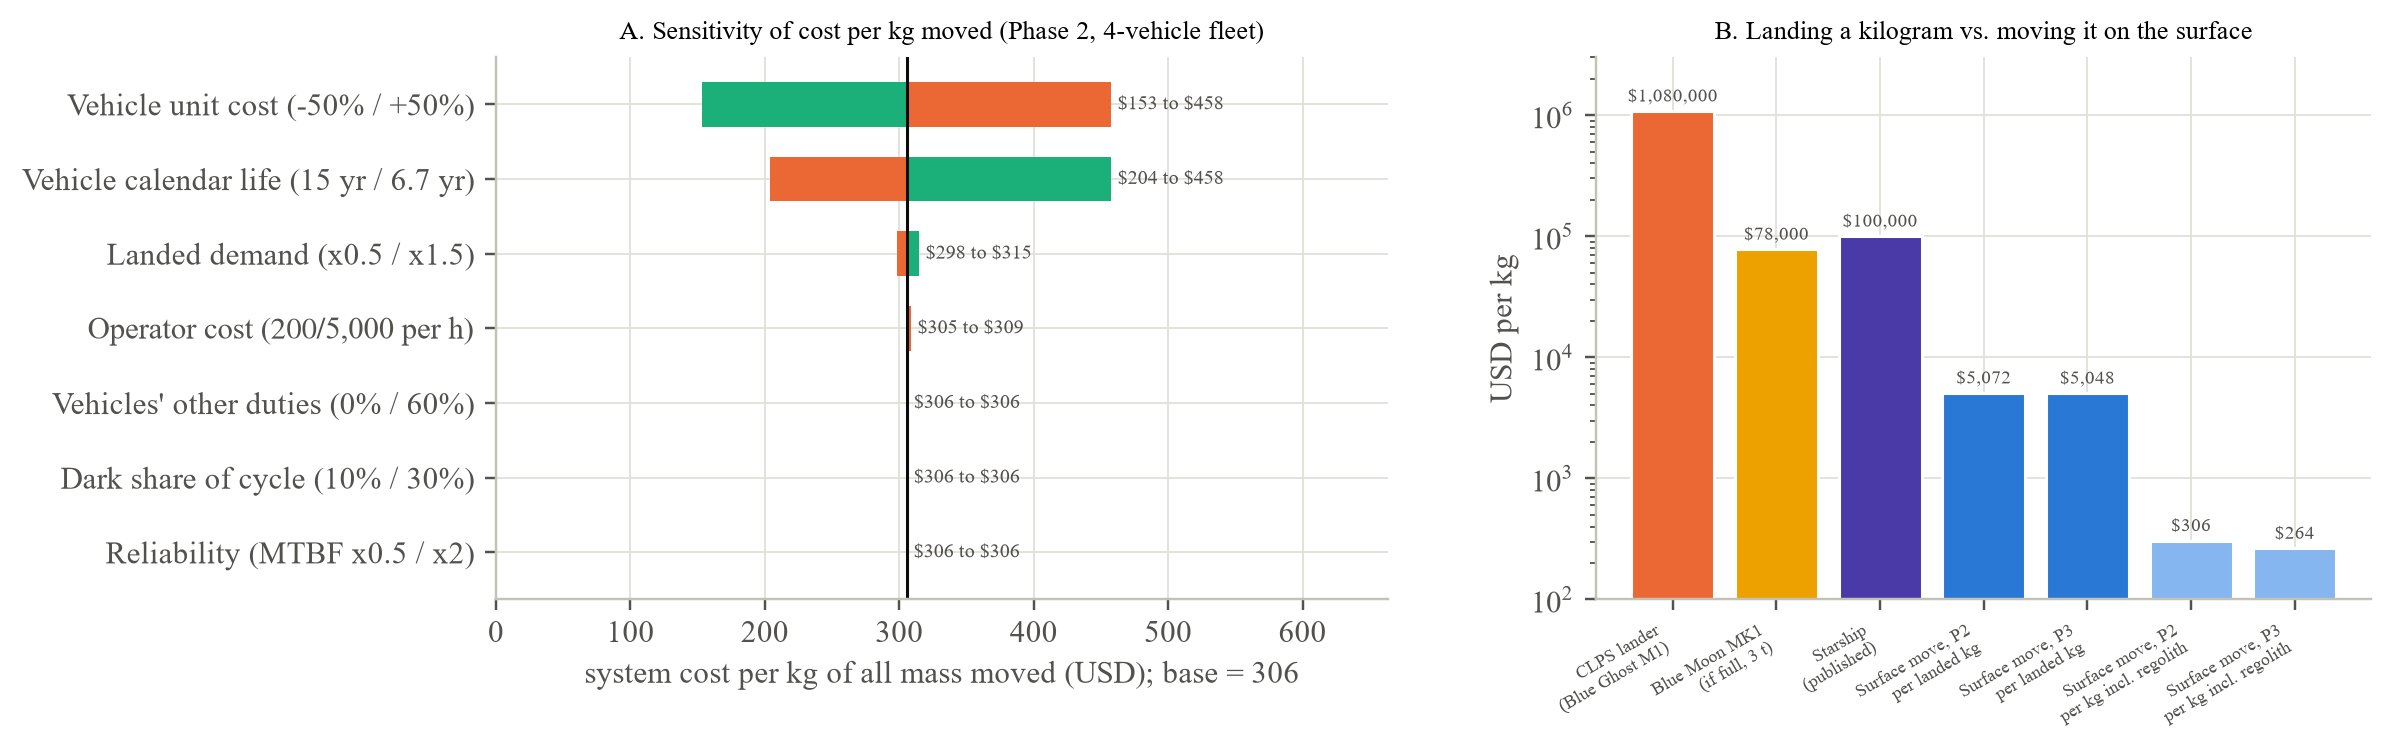
n: n = 30 seeds per cell · Intervals: none shown (cell means; the siting terms are deterministic given the means) · Flags: hauling Modelled; energy price Assumed; pad cost Spec (Metzger & Autry 2022), independent of standoff; impacts/landing Modelled from Wittal et al. (OTPS 2022) anchors, shield 0.1 Assumed when PAD_A LOS to BASE is blocked; damage cost per impact Assumed; delay valuation Assumed (blended $/item-hour stand-in for the engine's per-priority vot_usd_per_h)
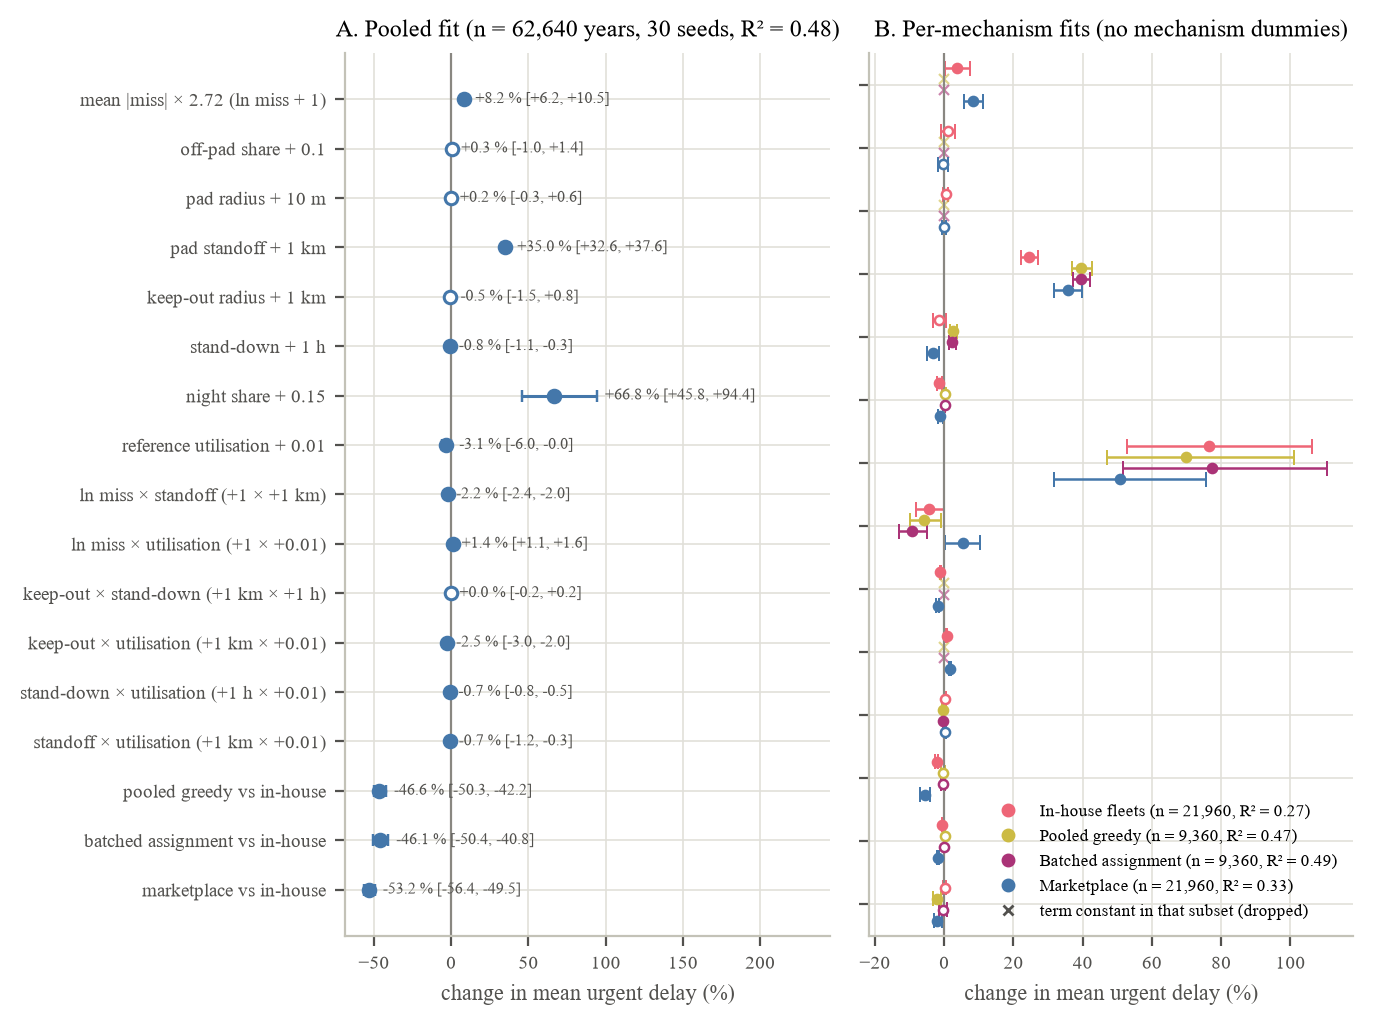
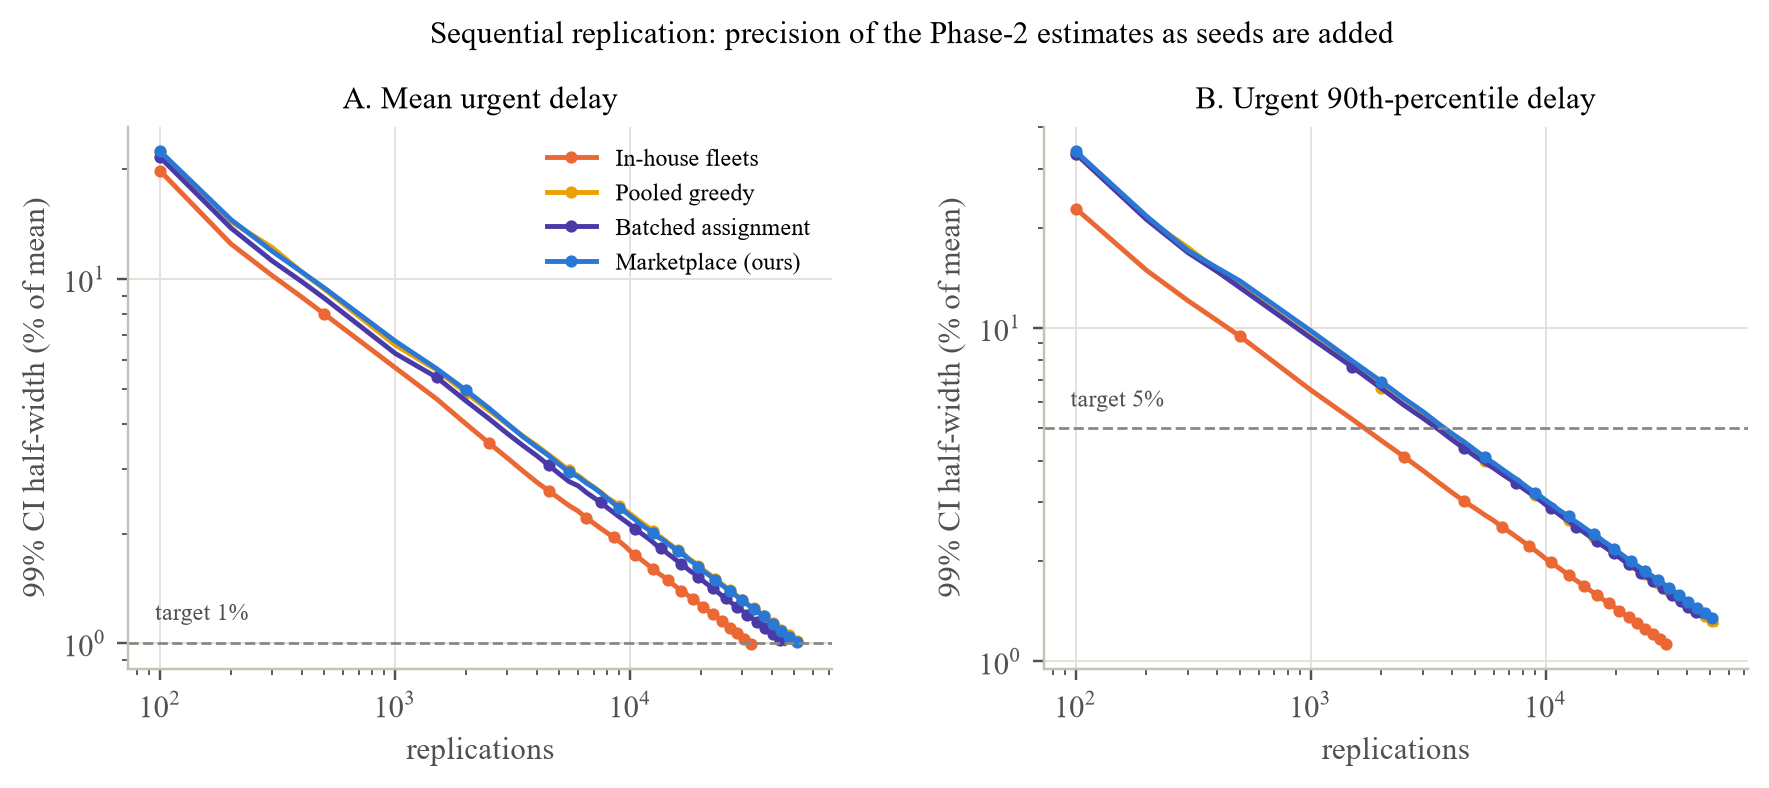
n: n = 62,640 simulated years from 30 seeds · Intervals: percentile seed-bootstrap 95 % CI (fit_law.fit_ols) · Flags: Modelled fit; Measured/Spec/Assumed levels
Lander Monte Carlo (E15)
| Class · controller | Episodes | Pass rate | Δ pass rate vs classical | Miss p50 | Miss p90 | Off the 50 m pad | Propellant | Failures (count) |
|---|---|---|---|---|---|---|---|---|
| CLPS · classical law | 500 | 93.8%Modelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E15.csv, classical_CLPS, n = 500 episodes) | reference | 2.2mModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E15.csv, classical_CLPS, n = 500 episodes) | 4.7mModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E15.csv, classical_CLPS, n = 500 episodes) | 0.4%Modelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E15.csv, classical_CLPS, n = 500 episodes) | 89kgModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E15.csv, classical_CLPS, n = 500 episodes) | velocity 14, sensor 6, timeout 11 |
| CLPS · classical law | 500 | 94.8%Modelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E15.csv, memoryless_CLPS, n = 500 episodes) | reference | 2.2mModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E15.csv, memoryless_CLPS, n = 500 episodes) | 4.7mModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E15.csv, memoryless_CLPS, n = 500 episodes) | 0.4%Modelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E15.csv, memoryless_CLPS, n = 500 episodes) | 85kgModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E15.csv, memoryless_CLPS, n = 500 episodes) | velocity 11, tilt 1, sensor 11, timeout 3 |
| CLPS · PPO, reward v2 | 500 | 63.2%Modelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E15.csv, lander_CLPS_baseline_s0, n = 500 episodes) | -30.6ppModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E15.csv, lander_CLPS_baseline_s0, n = 500 episodes) ± 4.7 | 4.0mModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E15.csv, lander_CLPS_baseline_s0, n = 500 episodes) | 7.8mModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E15.csv, lander_CLPS_baseline_s0, n = 500 episodes) | 1.2%Modelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E15.csv, lander_CLPS_baseline_s0, n = 500 episodes) | 61kgModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E15.csv, lander_CLPS_baseline_s0, n = 500 episodes) | velocity 52, tilt 22, sensor 110 |
| CLPS · imitation + DAgger, filtered teacher | 500 | 58.2%Modelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E15.csv, lander_CLPS_bc_s0, n = 500 episodes) | -35.6ppModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E15.csv, lander_CLPS_bc_s0, n = 500 episodes) ± 4.8 | 2.2mModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E15.csv, lander_CLPS_bc_s0, n = 500 episodes) | 5.1mModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E15.csv, lander_CLPS_bc_s0, n = 500 episodes) | 0.4%Modelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E15.csv, lander_CLPS_bc_s0, n = 500 episodes) | 86kgModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E15.csv, lander_CLPS_bc_s0, n = 500 episodes) | velocity 20, tilt 49, sensor 133, timeout 7 |
| CLPS · imitation + DAgger, observation v3 | 500 | 89.0%Modelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E15.csv, lander_CLPS_bc_v3_s0, n = 500 episodes) | -4.8ppModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E15.csv, lander_CLPS_bc_v3_s0, n = 500 episodes) ± 3.5 | 2.2mModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E15.csv, lander_CLPS_bc_v3_s0, n = 500 episodes) | 4.8mModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E15.csv, lander_CLPS_bc_v3_s0, n = 500 episodes) | 0.4%Modelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E15.csv, lander_CLPS_bc_v3_s0, n = 500 episodes) | 81kgModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E15.csv, lander_CLPS_bc_v3_s0, n = 500 episodes) | velocity 16, tilt 6, sensor 33 |
| CLPS · imitation + DAgger, memoryless teacher | 500 | 81.2%Modelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E15.csv, lander_CLPS_bcml_s0, n = 500 episodes) | -12.6ppModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E15.csv, lander_CLPS_bcml_s0, n = 500 episodes) ± 4.0 | 2.2mModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E15.csv, lander_CLPS_bcml_s0, n = 500 episodes) | 4.6mModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E15.csv, lander_CLPS_bcml_s0, n = 500 episodes) | 0.6%Modelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E15.csv, lander_CLPS_bcml_s0, n = 500 episodes) | 88kgModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E15.csv, lander_CLPS_bcml_s0, n = 500 episodes) | velocity 14, tilt 8, sensor 63, timeout 9 |
| CLPS · PPO, hover bonus (env v2) | 500 | 51.2%Modelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E15.csv, lander_CLPS_hover_bonus_s0, n = 500 episodes) | -42.6ppModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E15.csv, lander_CLPS_hover_bonus_s0, n = 500 episodes) ± 4.9 | 4.7mModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E15.csv, lander_CLPS_hover_bonus_s0, n = 500 episodes) | 10.3mModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E15.csv, lander_CLPS_hover_bonus_s0, n = 500 episodes) | 1.2%Modelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E15.csv, lander_CLPS_hover_bonus_s0, n = 500 episodes) | 63kgModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E15.csv, lander_CLPS_hover_bonus_s0, n = 500 episodes) | velocity 59, tilt 45, sensor 140 |
| CLPS · PPO, hover bonus (env v1) | 300 | 6.3%Modelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E15.csv, lander_CLPS_hover_bonus_v1_s0, n = 300 episodes) | -87.5ppModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E15.csv, lander_CLPS_hover_bonus_v1_s0, n = 300 episodes) ± 3.5 | 3.5mModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E15.csv, lander_CLPS_hover_bonus_v1_s0, n = 300 episodes) | 8.4mModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E15.csv, lander_CLPS_hover_bonus_v1_s0, n = 300 episodes) | 1.0%Modelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E15.csv, lander_CLPS_hover_bonus_v1_s0, n = 300 episodes) | 145kgModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E15.csv, lander_CLPS_hover_bonus_v1_s0, n = 300 episodes) | velocity 15, tilt 13, sensor 25, timeout 228 |
| CLPS · PPO, no survival term | 500 | 0.0%Modelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E15.csv, lander_CLPS_no_eta_s0, n = 500 episodes) | -93.8ppModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E15.csv, lander_CLPS_no_eta_s0, n = 500 episodes) ± 2.1 | 9.3mModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E15.csv, lander_CLPS_no_eta_s0, n = 500 episodes) | 27.4mModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E15.csv, lander_CLPS_no_eta_s0, n = 500 episodes) | 3.6%Modelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E15.csv, lander_CLPS_no_eta_s0, n = 500 episodes) | 50kgModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E15.csv, lander_CLPS_no_eta_s0, n = 500 episodes) | velocity 500 |
| LARGE · classical law | 500 | 97.0%Modelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E15.csv, classical_LARGE, n = 500 episodes) | reference | 2.1mModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E15.csv, classical_LARGE, n = 500 episodes) | 4.4mModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E15.csv, classical_LARGE, n = 500 episodes) | 0.0%Modelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E15.csv, classical_LARGE, n = 500 episodes) | 2,297kgModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E15.csv, classical_LARGE, n = 500 episodes) | velocity 1, sensor 9, timeout 5 |
| MK1 · classical law | 500 | 93.0%Modelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E15.csv, classical_MK1, n = 500 episodes) | reference | 2.1mModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E15.csv, classical_MK1, n = 500 episodes) | 4.4mModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E15.csv, classical_MK1, n = 500 episodes) | 0.0%Modelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E15.csv, classical_MK1, n = 500 episodes) | 298kgModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E15.csv, classical_MK1, n = 500 episodes) | sensor 19, timeout 16 |
Flags: environment Modelled (3-DoF descent parameterised from flown landers), failure limits Spec, learned policies trained in-house (Modelled); sensor noise on in every row. table_E15.csv · per-episode outcome tables: data/policies/outcomes_*.json (repository).
Driving-table validation (E16)
| Autonomy | Round trip | Simulated | Mean of runs | Ratio to 0 s | Reference | Error | Interventions λ | Stops |
|---|---|---|---|---|---|---|---|---|
| teleop | 0 s | 3.26km/hModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E16.csv, speed_made_good_vs_rtt_flat, synthetic flat 2 km, teleop 0.0 s) | 3.25km/hModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E16.csv, speed_made_good_vs_rtt_flat, synthetic flat 2 km, teleop 0.0 s) | 1.000 | 3.24km/hMeasured (Measured: observed on flown hardware or in a published test. Source: Litaker et al. 2025, JSC teleoperation simulator (speed made good)) | 0.66 % | 0.10 | 10 |
| teleop | 4 s | 2.57km/hModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E16.csv, speed_made_good_vs_rtt_flat, synthetic flat 2 km, teleop 4.0 s) | 2.56km/hModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E16.csv, speed_made_good_vs_rtt_flat, synthetic flat 2 km, teleop 4.0 s) | 0.788 | 2.56km/hMeasured (Measured: observed on flown hardware or in a published test. Source: Litaker et al. 2025, JSC teleoperation simulator (speed made good)) | 0.38 % | 0.10 | 20 |
| teleop | 6 s | 2.03km/hModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E16.csv, speed_made_good_vs_rtt_flat, synthetic flat 2 km, teleop 6.0 s) | 2.02km/hModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E16.csv, speed_made_good_vs_rtt_flat, synthetic flat 2 km, teleop 6.0 s) | 0.623 | 2.03km/hMeasured (Measured: observed on flown hardware or in a published test. Source: Litaker et al. 2025, JSC teleoperation simulator (speed made good)) | 0.07 % | 0.10 | 34 |
| teleop | 8 s | 1.76km/hModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E16.csv, speed_made_good_vs_rtt_flat, synthetic flat 2 km, teleop 8.0 s) | 1.76km/hModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E16.csv, speed_made_good_vs_rtt_flat, synthetic flat 2 km, teleop 8.0 s) | 0.541 | 1.76km/hMeasured (Measured: observed on flown hardware or in a published test. Source: Litaker et al. 2025, JSC teleoperation simulator (speed made good)) | 0.20 % | 0.10 | 41 |
| supervised | 0 s | 2.71km/hModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E16.csv, speed_made_good_vs_rtt_flat, synthetic flat 2 km, supervised 0.0 s) | 2.70km/hModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E16.csv, speed_made_good_vs_rtt_flat, synthetic flat 2 km, supervised 0.0 s) | 1.000 | – | – | 0.20 | 4 |
| supervised | 4 s | 2.71km/hModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E16.csv, speed_made_good_vs_rtt_flat, synthetic flat 2 km, supervised 4.0 s) | 2.70km/hModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E16.csv, speed_made_good_vs_rtt_flat, synthetic flat 2 km, supervised 4.0 s) | 1.000 | – | – | 0.20 | 4 |
| supervised | 6 s | 2.71km/hModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E16.csv, speed_made_good_vs_rtt_flat, synthetic flat 2 km, supervised 6.0 s) | 2.70km/hModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E16.csv, speed_made_good_vs_rtt_flat, synthetic flat 2 km, supervised 6.0 s) | 1.000 | – | – | 0.20 | 4 |
| supervised | 8 s | 2.71km/hModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E16.csv, speed_made_good_vs_rtt_flat, synthetic flat 2 km, supervised 8.0 s) | 2.70km/hModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E16.csv, speed_made_good_vs_rtt_flat, synthetic flat 2 km, supervised 8.0 s) | 1.000 | – | – | 0.20 | 4 |
| autonomous | 0 s | 8.94km/hModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E16.csv, speed_made_good_vs_rtt_flat, synthetic flat 2 km, autonomous 0.0 s) | 8.89km/hModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E16.csv, speed_made_good_vs_rtt_flat, synthetic flat 2 km, autonomous 0.0 s) | 1.000 | – | – | 0.40 | 0 |
| autonomous | 4 s | 8.94km/hModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E16.csv, speed_made_good_vs_rtt_flat, synthetic flat 2 km, autonomous 4.0 s) | 8.89km/hModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E16.csv, speed_made_good_vs_rtt_flat, synthetic flat 2 km, autonomous 4.0 s) | 1.000 | – | – | 0.40 | 0 |
| autonomous | 6 s | 8.94km/hModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E16.csv, speed_made_good_vs_rtt_flat, synthetic flat 2 km, autonomous 6.0 s) | 8.89km/hModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E16.csv, speed_made_good_vs_rtt_flat, synthetic flat 2 km, autonomous 6.0 s) | 1.000 | – | – | 0.40 | 0 |
| autonomous | 8 s | 8.94km/hModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E16.csv, speed_made_good_vs_rtt_flat, synthetic flat 2 km, autonomous 8.0 s) | 8.89km/hModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E16.csv, speed_made_good_vs_rtt_flat, synthetic flat 2 km, autonomous 8.0 s) | 1.000 | – | – | 0.40 | 0 |
flat ground as calibrated (Litaker/JSC teleop, Measured); same integrator as driving-v1; sim_kmh is the deterministic made-good with whole stops, sim_kmh_mean_runs the mean over 400 runs
| Autonomy | Round trip | Simulated | Mean of runs | Ratio to 0 s | Reference | Error | Interventions λ | Stops |
|---|---|---|---|---|---|---|---|---|
| autonomous | 0 s | 7.93km/hModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E16.csv, speed_made_good_vs_rtt_real_leg, CONSTR->DEPOT, autonomous 0.0 s) | – | 1.000 | – | – | 0.10 | – |
| autonomous | 4 s | 8.00km/hModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E16.csv, speed_made_good_vs_rtt_real_leg, CONSTR->DEPOT, autonomous 4.0 s) | – | 1.009 | – | – | 0.10 | – |
| autonomous | 6 s | 7.81km/hModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E16.csv, speed_made_good_vs_rtt_real_leg, CONSTR->DEPOT, autonomous 6.0 s) | – | 0.984 | – | – | 0.00 | – |
| autonomous | 8 s | 8.04km/hModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E16.csv, speed_made_good_vs_rtt_real_leg, CONSTR->DEPOT, autonomous 8.0 s) | – | 1.014 | – | – | 0.05 | – |
| supervised | 0 s | 2.47km/hModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E16.csv, speed_made_good_vs_rtt_real_leg, CONSTR->DEPOT, supervised 0.0 s) | – | 1.000 | – | – | 0.10 | – |
| supervised | 4 s | 2.41km/hModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E16.csv, speed_made_good_vs_rtt_real_leg, CONSTR->DEPOT, supervised 4.0 s) | – | 0.974 | – | – | 0.05 | – |
| supervised | 6 s | 2.51km/hModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E16.csv, speed_made_good_vs_rtt_real_leg, CONSTR->DEPOT, supervised 6.0 s) | – | 1.018 | – | – | 0.15 | – |
| supervised | 8 s | 2.47km/hModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E16.csv, speed_made_good_vs_rtt_real_leg, CONSTR->DEPOT, supervised 8.0 s) | – | 1.001 | – | – | 0.10 | – |
| teleop | 0 s | 3.01km/hModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E16.csv, speed_made_good_vs_rtt_real_leg, CONSTR->DEPOT, teleop 0.0 s) | – | 1.000 | 3.24km/hMeasured (Measured: observed on flown hardware or in a published test. Source: Litaker et al. 2025, JSC teleoperation simulator (speed made good)) | -7.12 % | 0.05 | – |
| teleop | 4 s | 2.39km/hModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E16.csv, speed_made_good_vs_rtt_real_leg, CONSTR->DEPOT, teleop 4.0 s) | – | 0.793 | 2.56km/hMeasured (Measured: observed on flown hardware or in a published test. Source: Litaker et al. 2025, JSC teleoperation simulator (speed made good)) | -6.82 % | 0.10 | – |
| teleop | 6 s | 1.88km/hModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E16.csv, speed_made_good_vs_rtt_real_leg, CONSTR->DEPOT, teleop 6.0 s) | – | 0.626 | 2.03km/hMeasured (Measured: observed on flown hardware or in a published test. Source: Litaker et al. 2025, JSC teleoperation simulator (speed made good)) | -7.19 % | 0.00 | – |
| teleop | 8 s | 1.68km/hModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E16.csv, speed_made_good_vs_rtt_real_leg, CONSTR->DEPOT, teleop 8.0 s) | – | 0.558 | 1.76km/hMeasured (Measured: observed on flown hardware or in a published test. Source: Litaker et al. 2025, JSC teleoperation simulator (speed made good)) | -4.67 % | 0.00 | – |
context: flattest real leg >= 500 m (max slope 5.8 deg, so below the flat-ground reference); table time excludes interventions
| Case | Simulated | Reference band | In band |
|---|---|---|---|
| autonomous, 4.0 s, day | 1.77kWhModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E16.csv, psr_round_trip_energy, BASE->PSR + PSR->BASE, autonomous 4.0 s) | 1.3–14.1 kWh | yes |
| autonomous, 4.0 s, night | 1.89kWhModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E16.csv, psr_round_trip_energy, BASE->PSR + PSR->BASE, autonomous 4.0 s) | 1.3–14.1 kWh | yes |
| supervised, 4.0 s, day | 1.83kWhModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E16.csv, psr_round_trip_energy, BASE->PSR + PSR->BASE, supervised 4.0 s) | 1.3–14.1 kWh | yes |
| supervised, 4.0 s, night | 1.86kWhModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E16.csv, psr_round_trip_energy, BASE->PSR + PSR->BASE, supervised 4.0 s) | 1.3–14.1 kWh | yes |
| teleop, 4.0 s, day | 1.84kWhModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E16.csv, psr_round_trip_energy, BASE->PSR + PSR->BASE, teleop 4.0 s) | 1.3–14.1 kWh | yes |
| teleop, 4.0 s, night | 1.77kWhModelled (Modelled: produced by the LunarHaul simulation. Source: results/table_E16.csv, psr_round_trip_energy, BASE->PSR + PSR->BASE, teleop 4.0 s) | 1.3–14.1 kWh | yes |
Chen 2026 band 0.4-4.4 kWh at 500 kg scaled x3.2 (rolling + grade losses scale with m*g: Assumed linear); table energy is traction only
Flags: simulated values Modelled (rover model and driving tables, lunarsim.rover); teleoperation references Measured. table_E16.csv · raw runs: E16_driving_validation.csv (repository).
Version 2 results
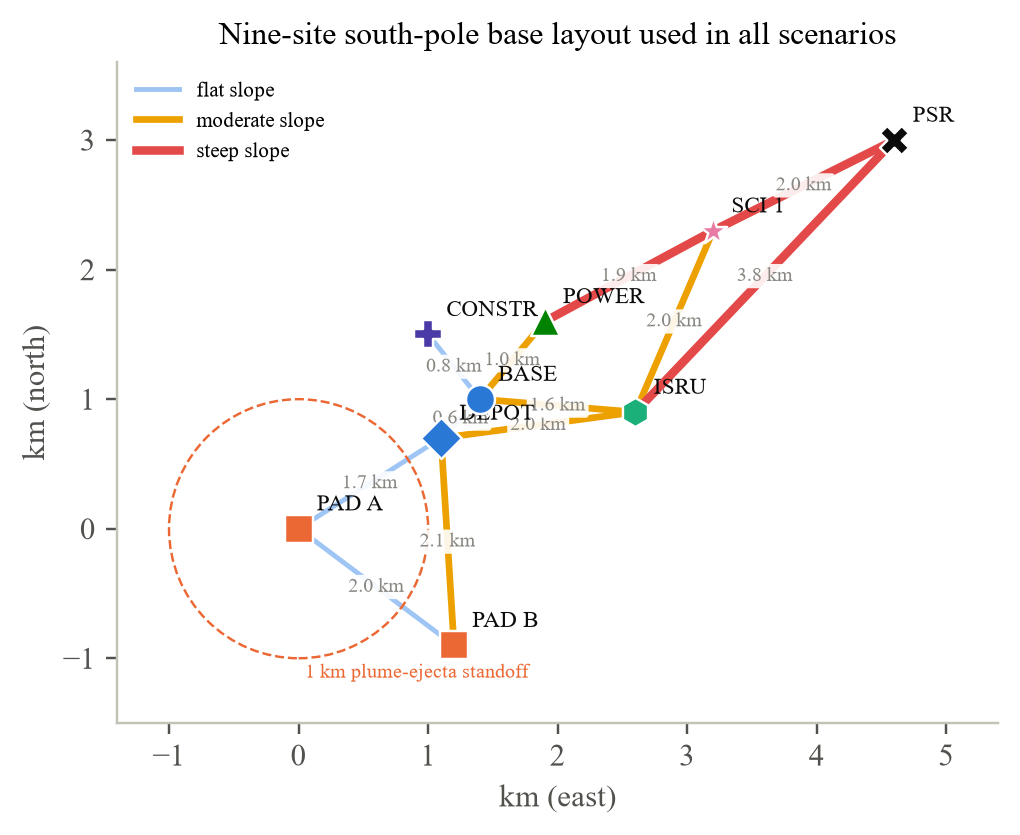
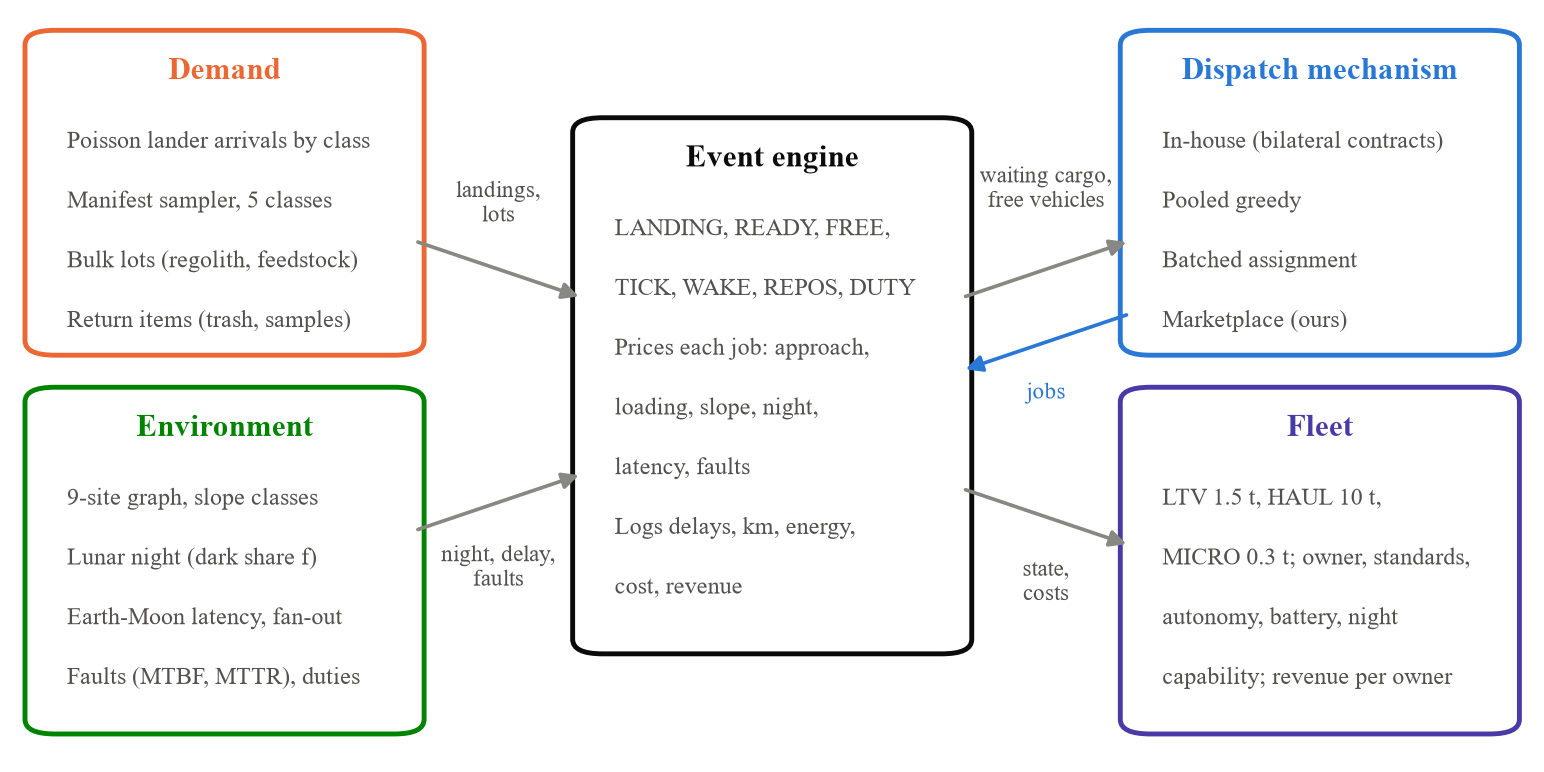
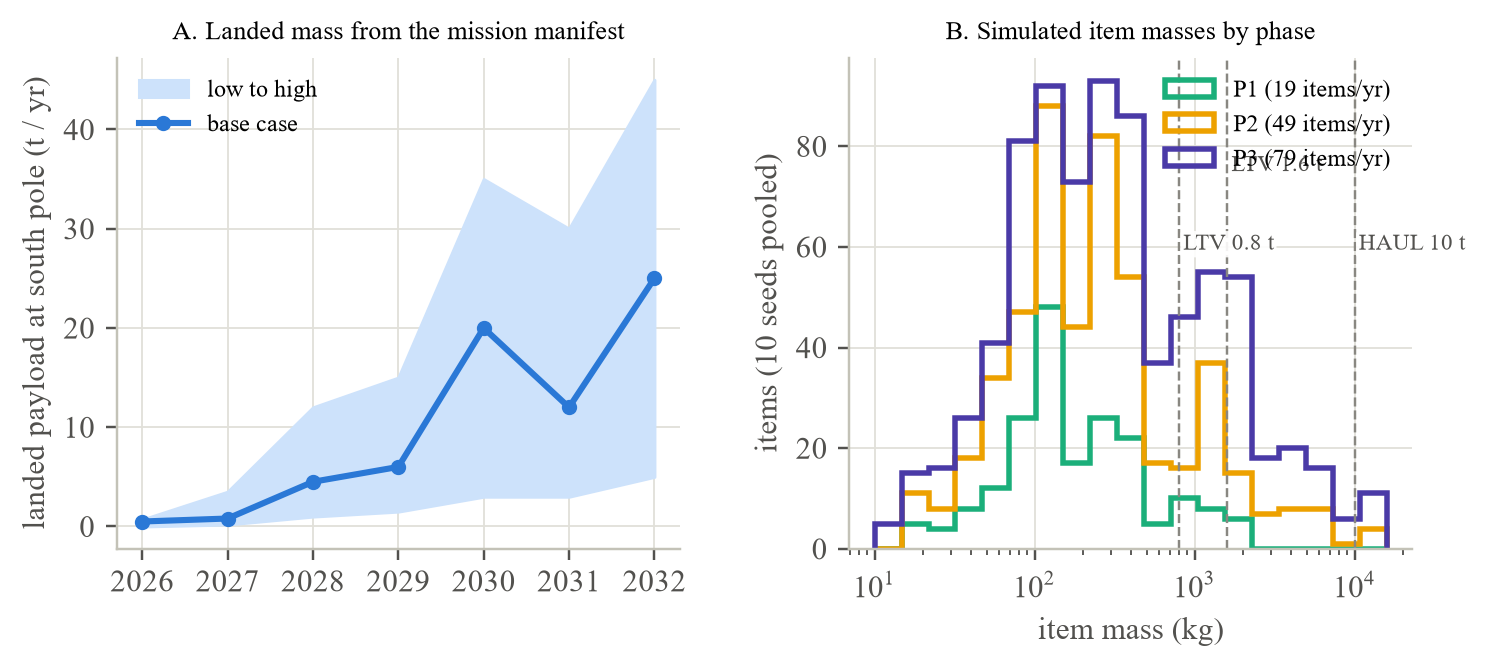
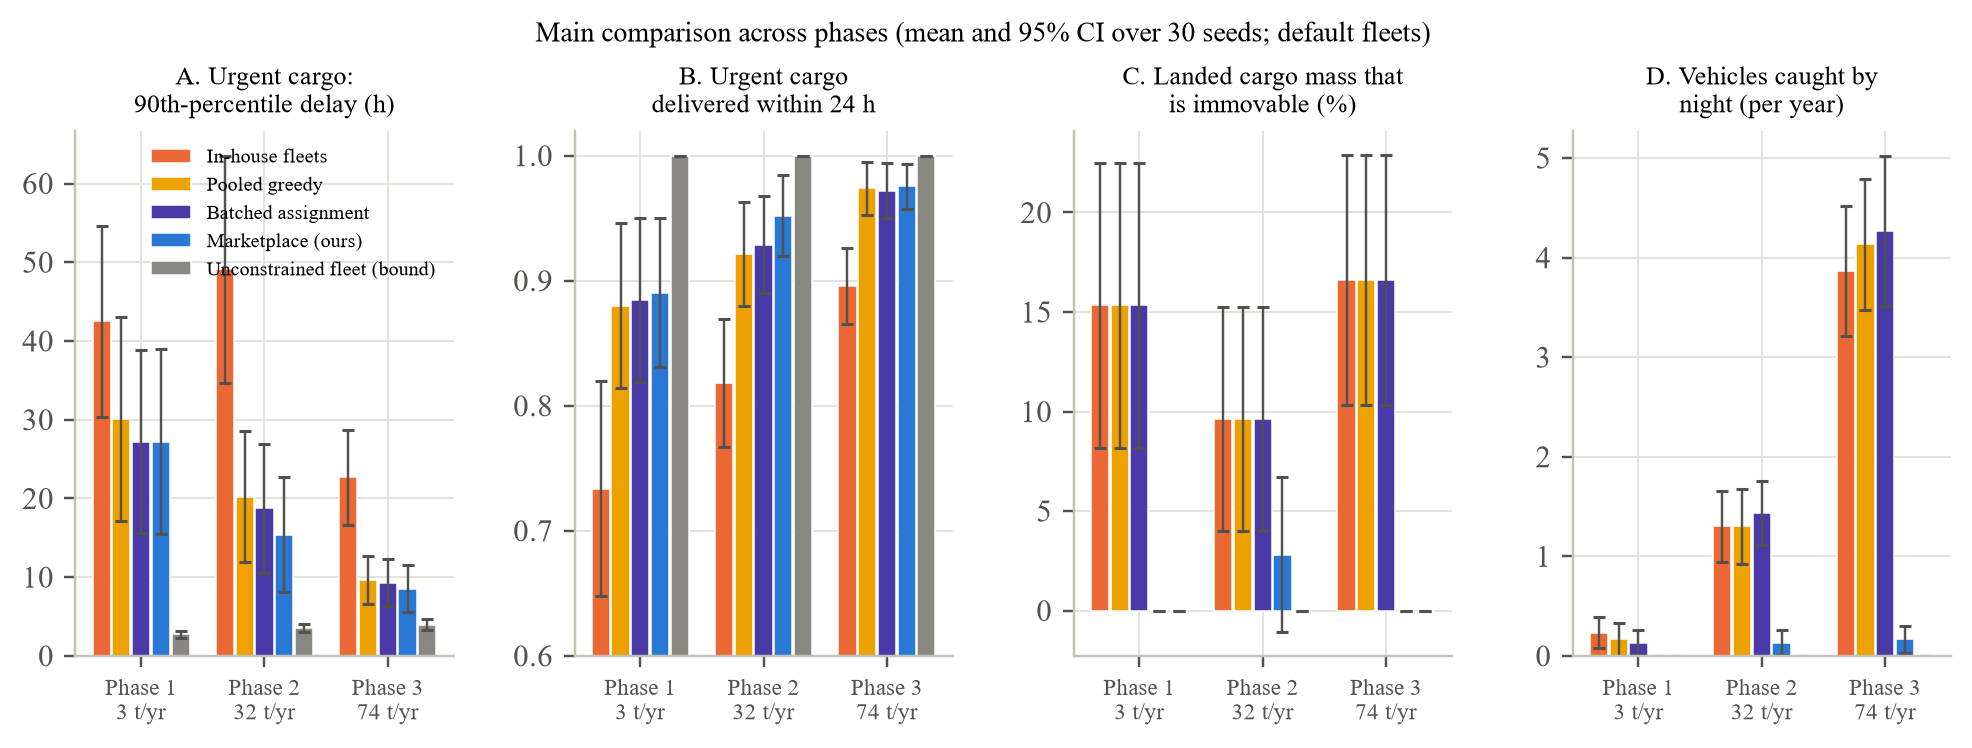
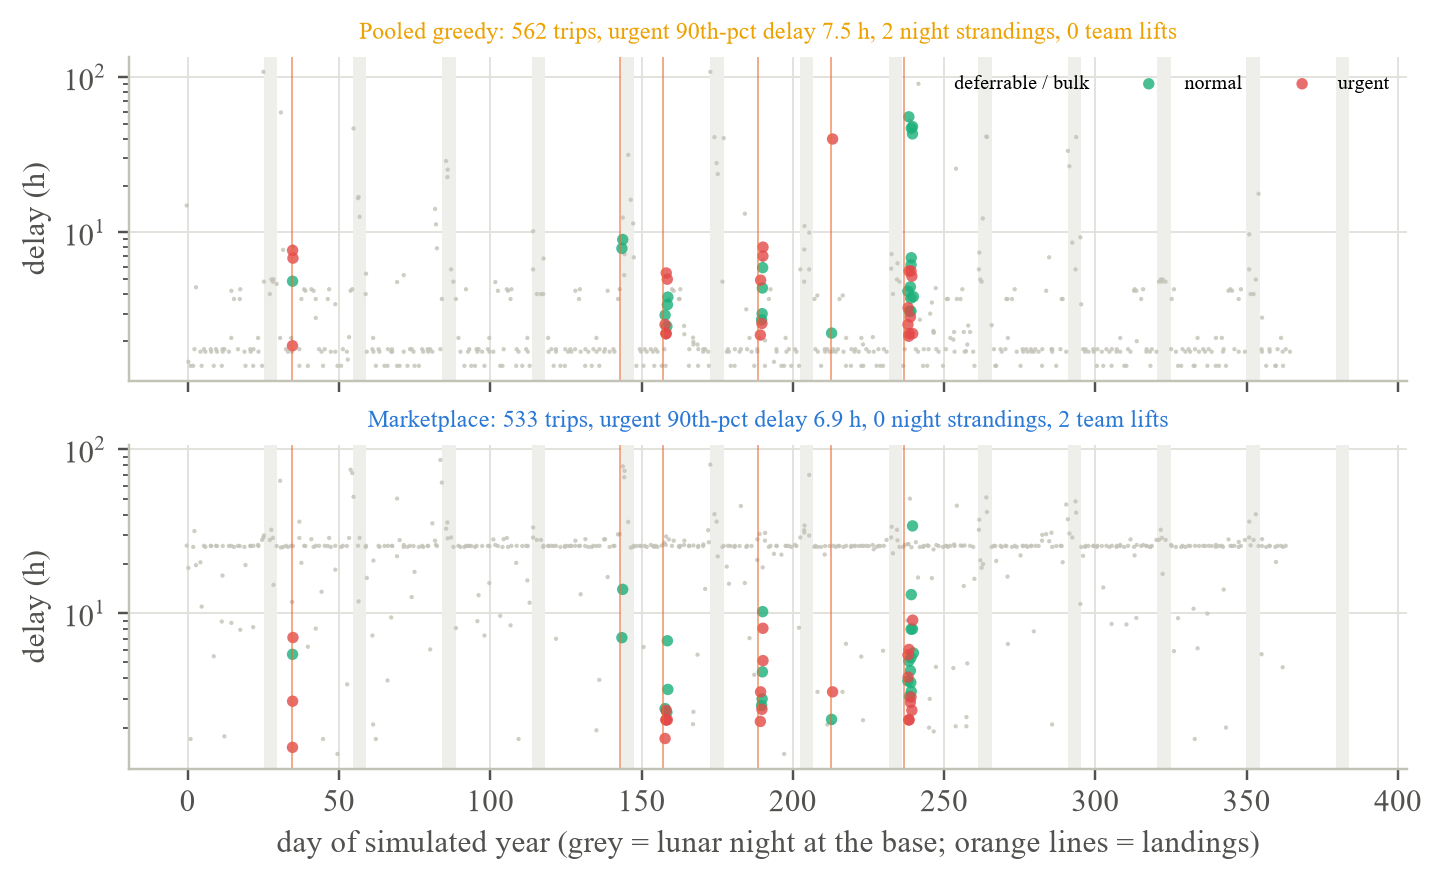
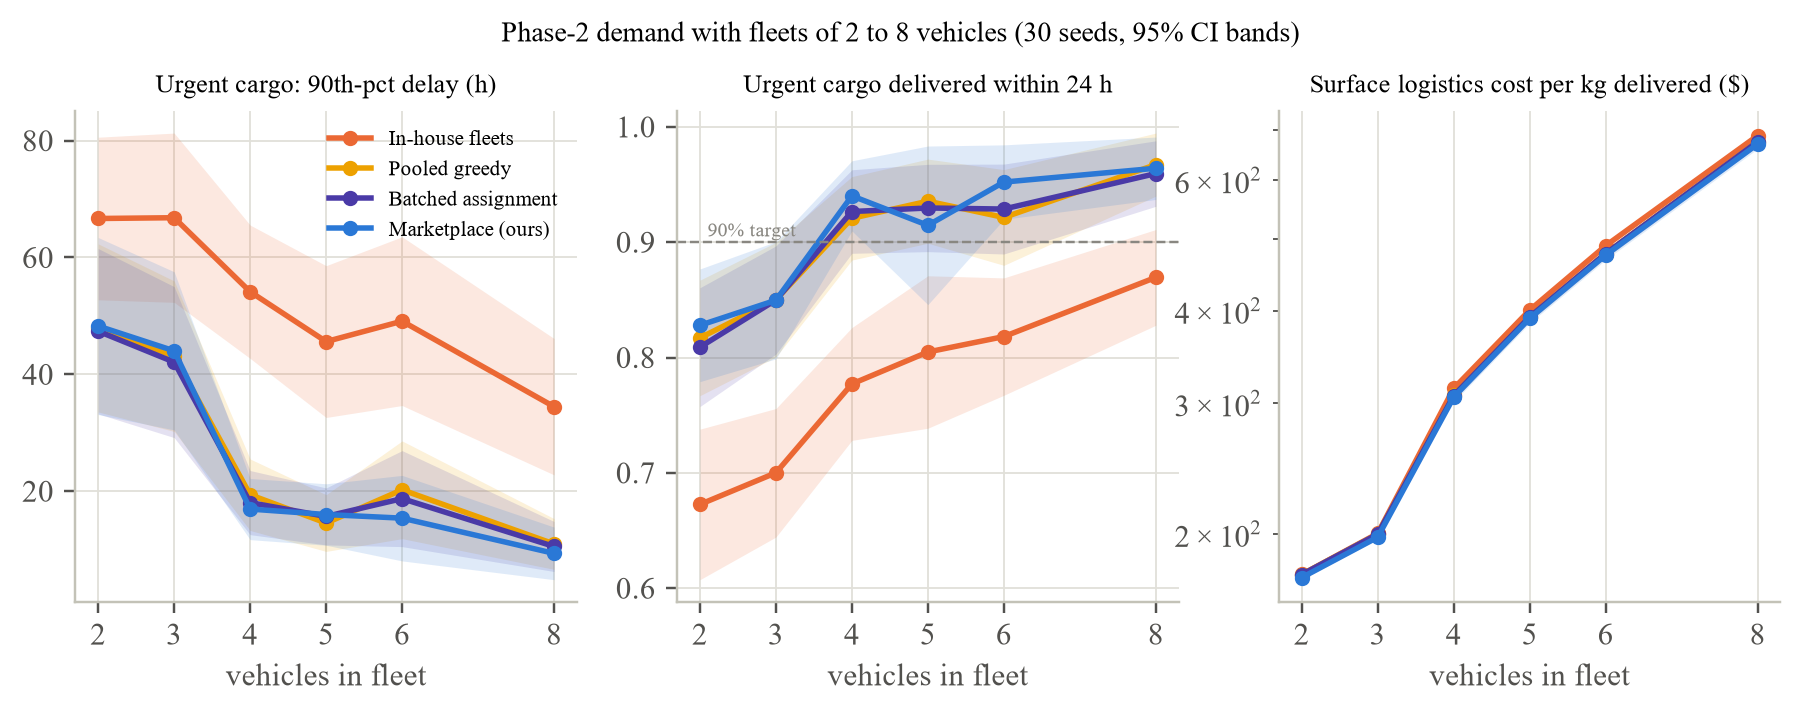
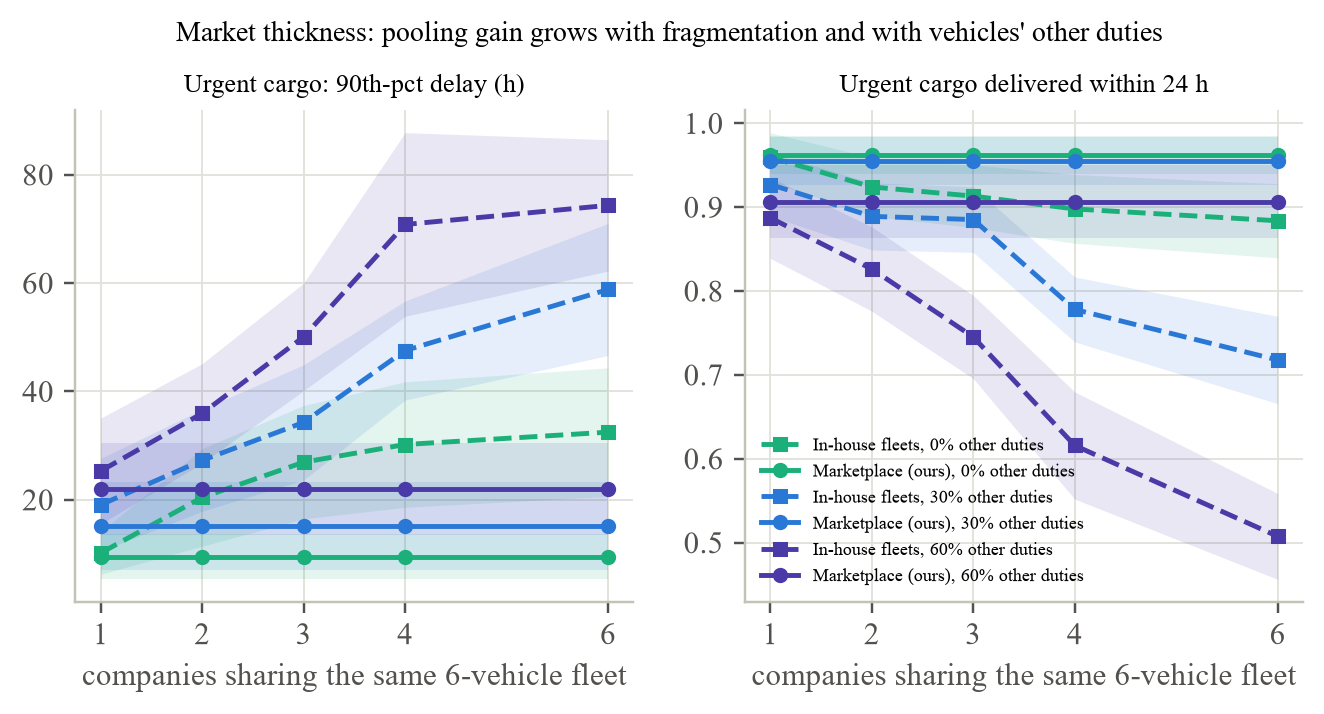
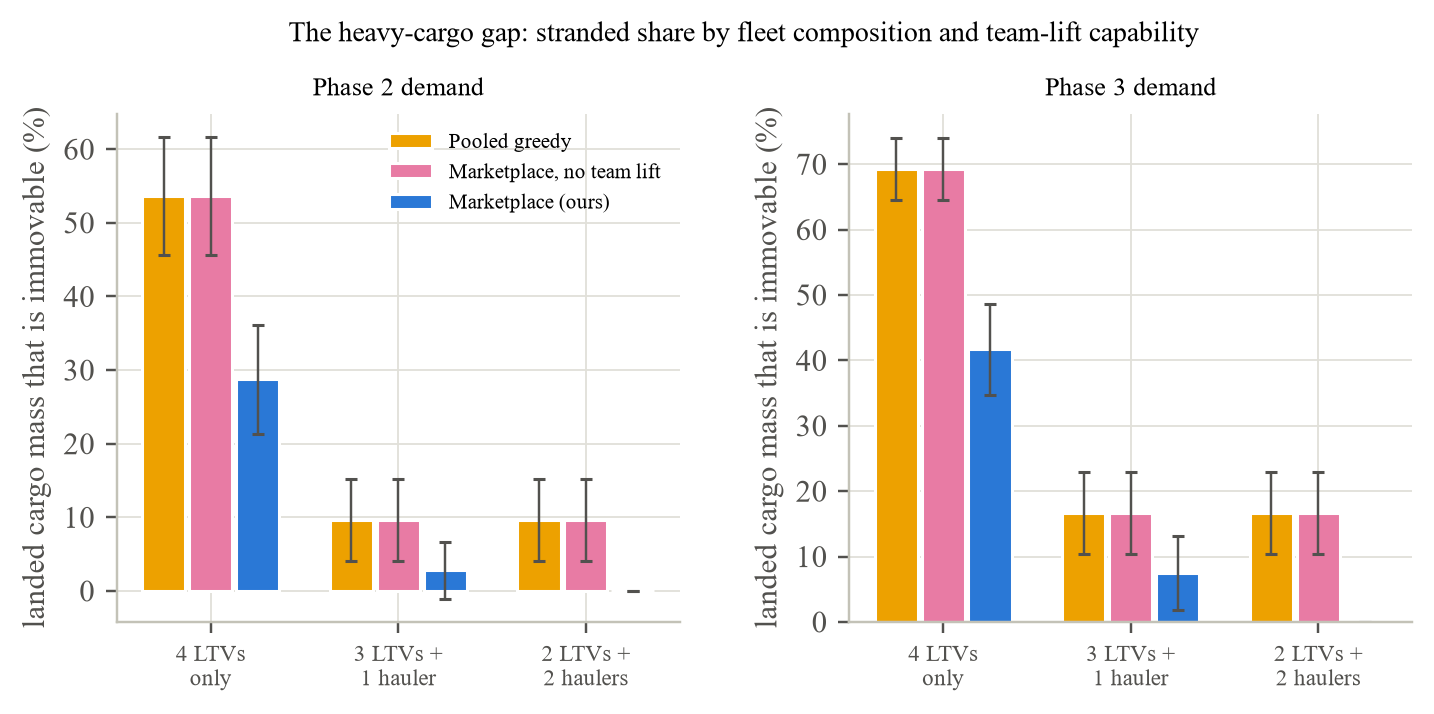
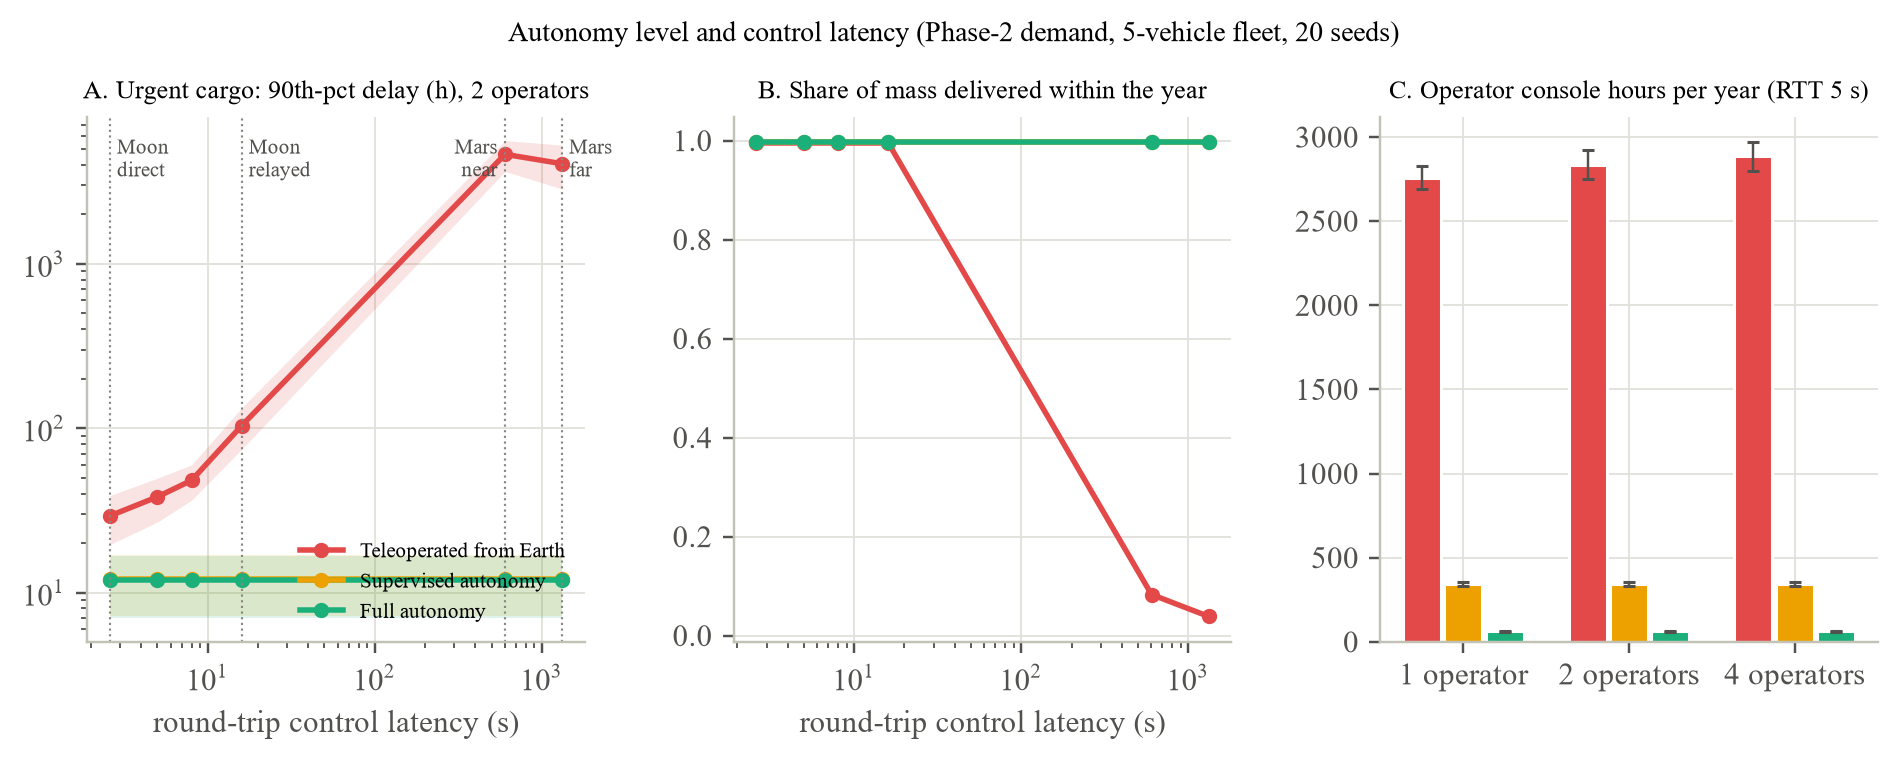
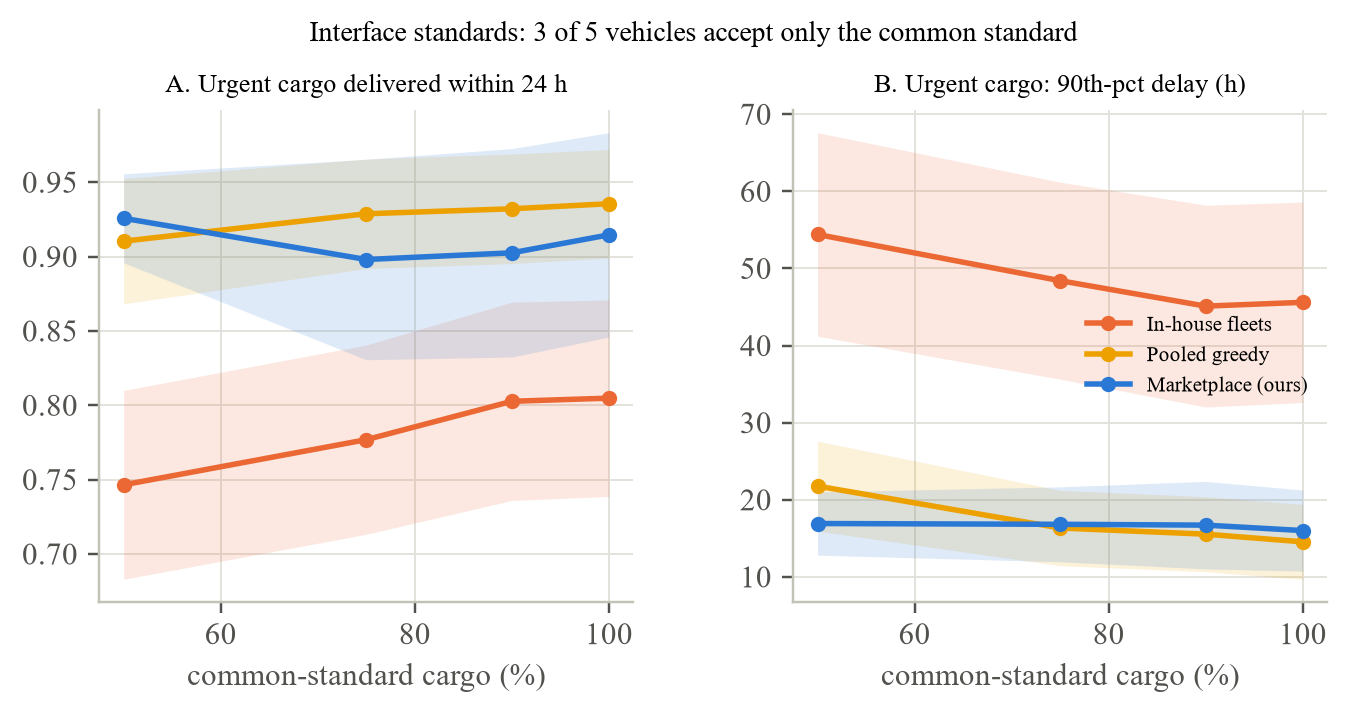
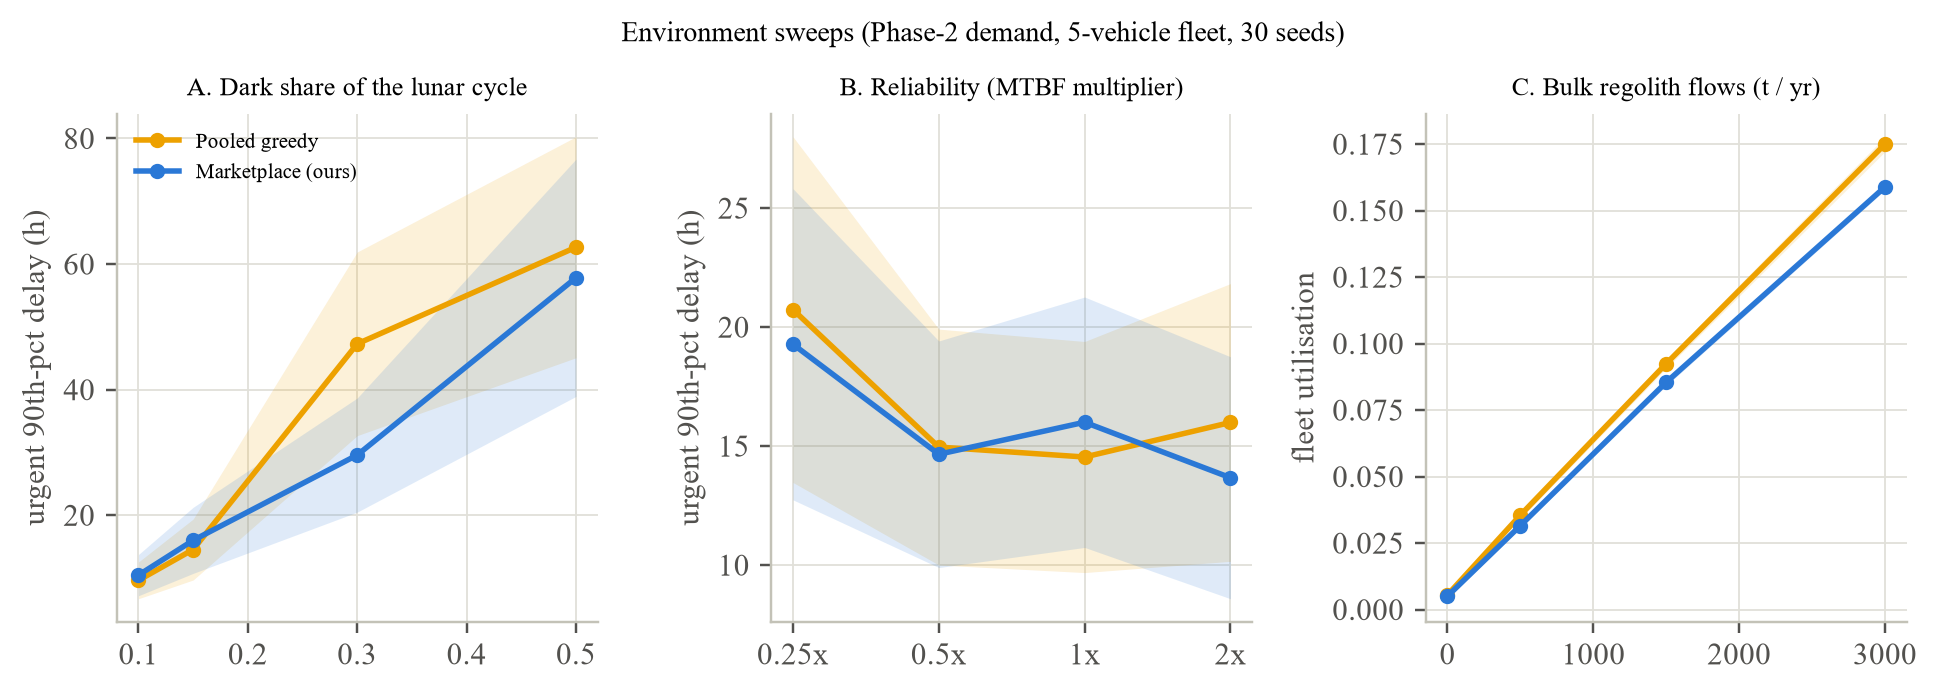
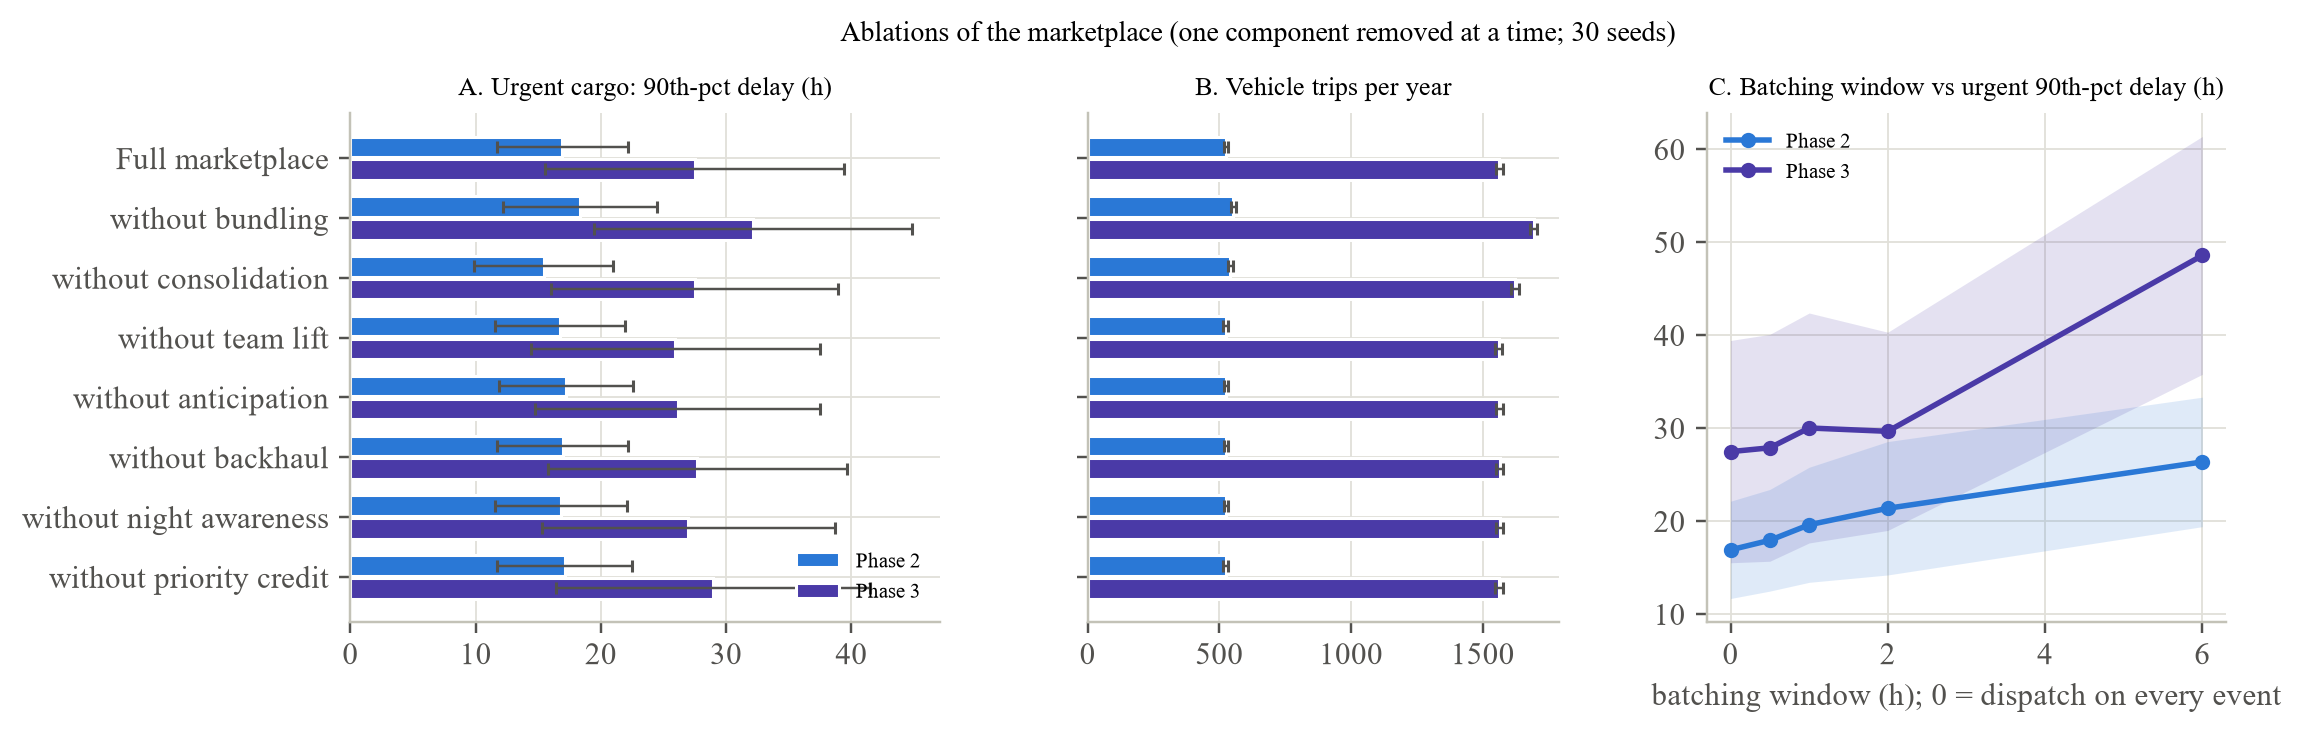
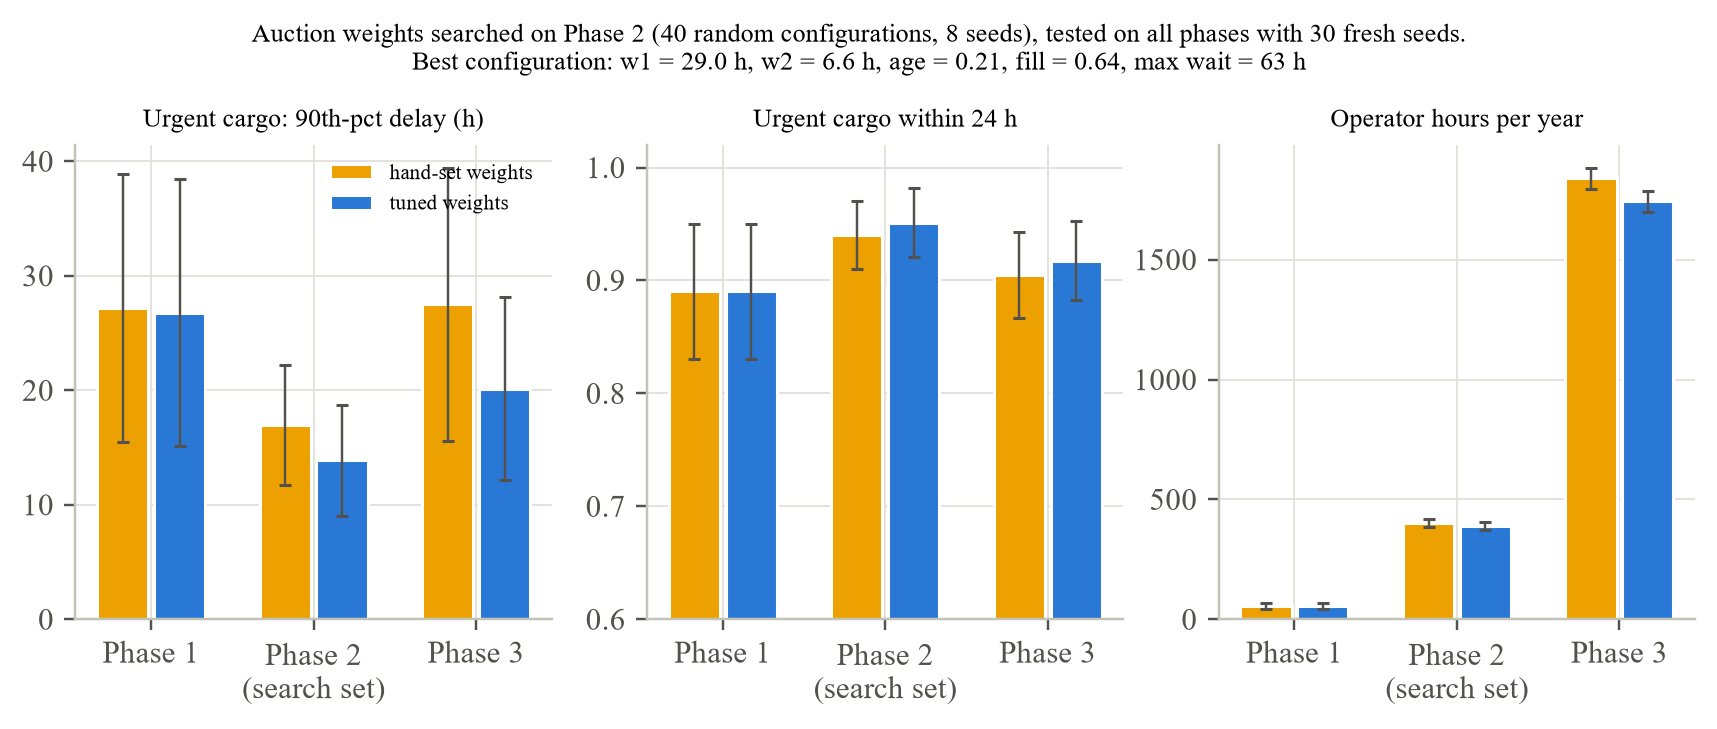
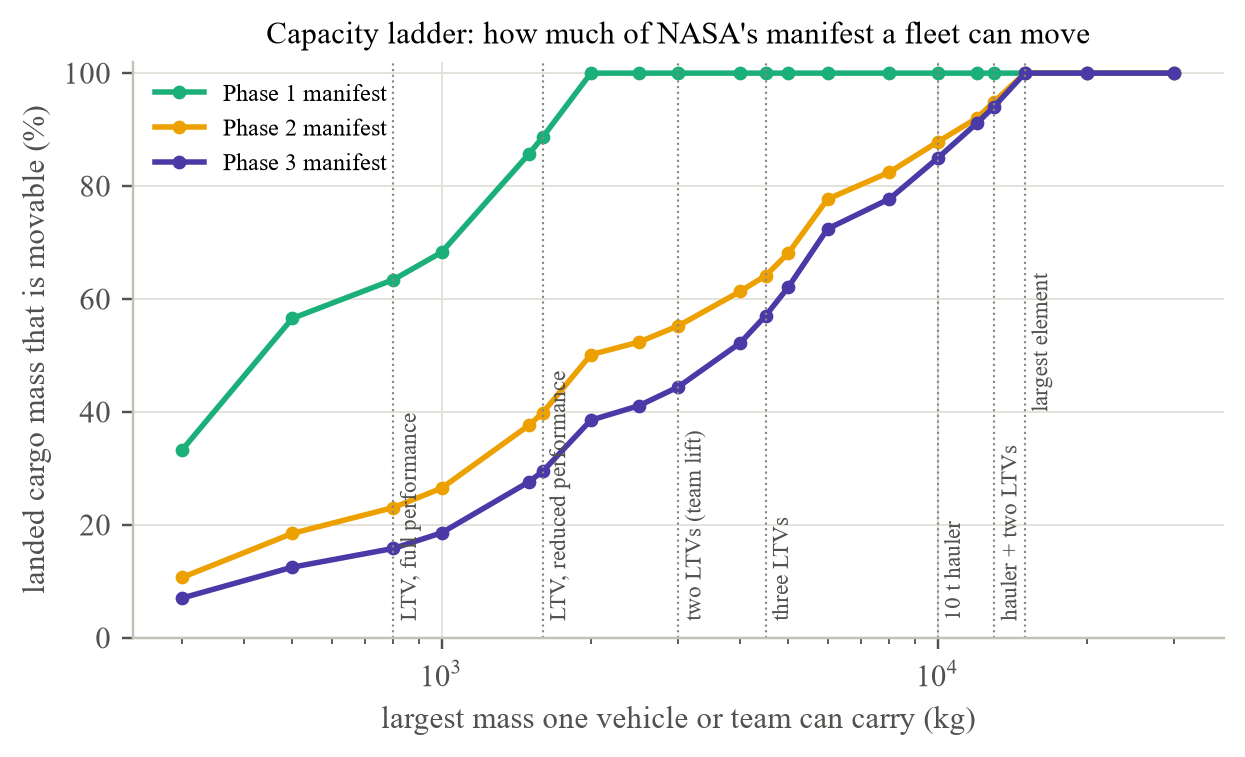
Show the 19 figures of the version-2 paper (marketplace dispatch on an abstract site graph)
Captions from the version-2 paper. The engine and these results are unchanged in Phase 3 (lunarsim compare reproduces them).